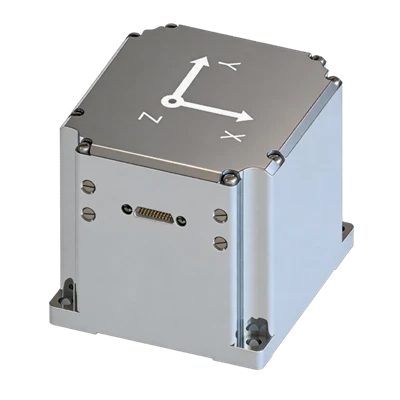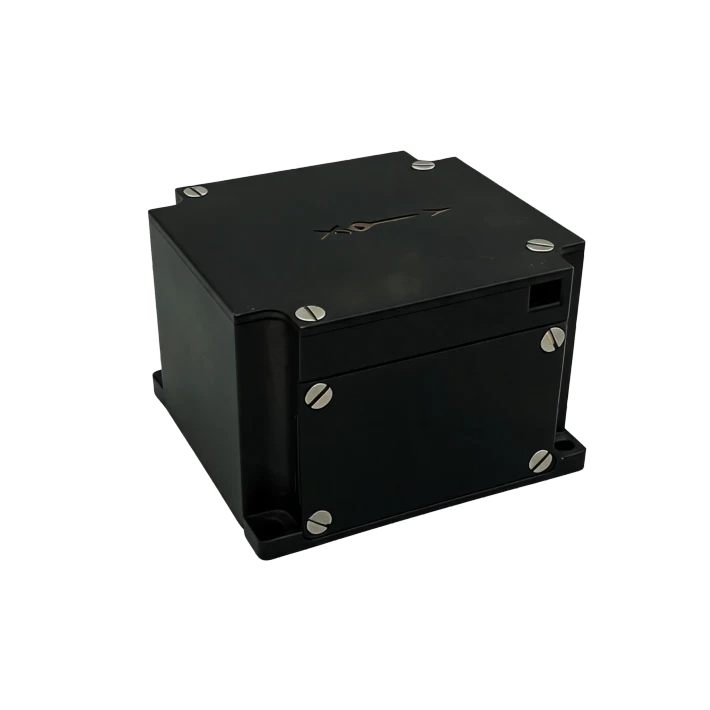
F3X100 Three-Axis FOG IMU
All-solid-state design
Robust environmental adaptability
High reliability, ultra-long lifetime
Description
Key Features
- Compact micro design
- All-solid-state design
- Robust environmental adaptability
- High reliability, ultra-long lifetime
- Full digital RS-422 electrical interface
Applications
- Mobile survey & attitude
- Unmanned systems (ground/marine/UW)
- Surveying & north-finding
- Stabilized platforms
- SATCOM-on-the-move
- Autonomous driving & munitions
Product Introduction
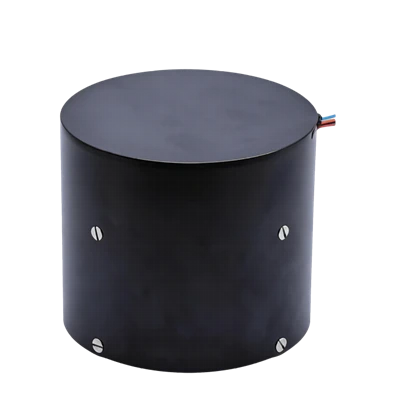
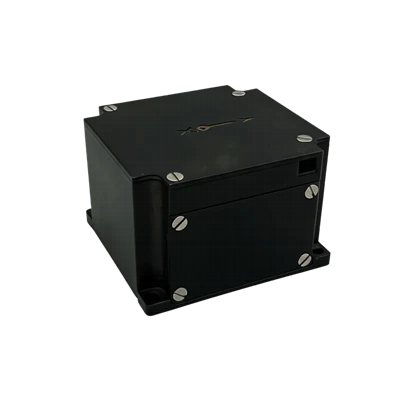
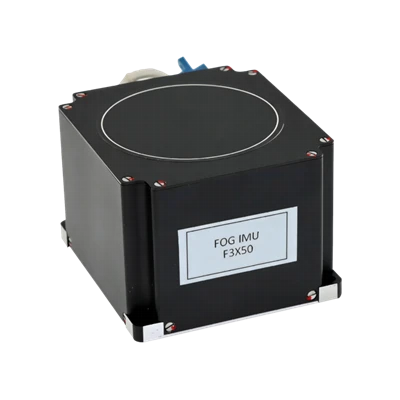
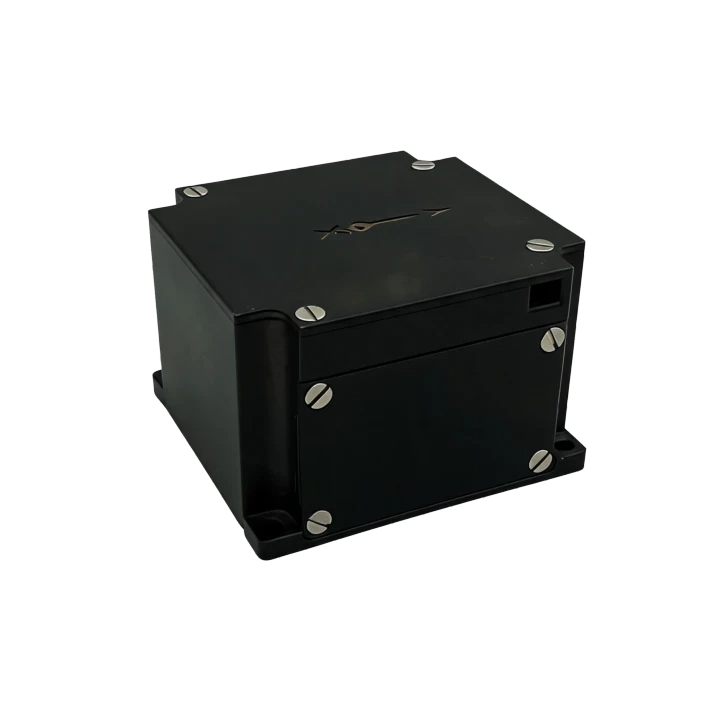
Company's F3X100 is a three-axis FOG IMU purpose-built for the navigation, guidance, and attitude control systems of small missiles and guided bombs. Comprising three all-solid-state FOGs, three quartz accelerometers, and a data packaging board, it measures angular velocity and linear acceleration to support attitude and navigation control. Its all-solid-state architecture eliminates moving parts for excellent shock and vibration resistance, and RS-422 serial output enables seamless system integration in high-dynamic precision guidance and attitude measurement applications.
Unique Technology
Company is a high-tech enterprise with full closed-loop capabilities from fiber winding equipment and coils to FOGs, fiber/MEMS inertial products, IMU circuits, software, and test equipment. End-to-end process control improves quality and reduces costs. Operating under ISO9001 with strict processes, it ensures product reliability and consistency.
F3X100 Three-Axis Fiber Optical Gyro IMU Performance Specifications
|
Parameter |
H |
M |
|
Fiber Optic Gyroscope |
|
|
|
RT Bias Repeatability (run-to-run, day-to-day) (°/h) |
≤0.05 |
≤0.1 |
|
Constant-Temp Bias Stability (°/h) |
≤0.05 |
≤0.1 |
|
RT SF Repeatability (ppm) |
≤20 |
≤20 |
|
Constant-Temp SF Asymmetry (ppm) |
≤20 |
≤20 |
|
Constant-Temp SF Nonlinearity (ppm) |
≤30 |
≤30 |
|
Threshold (°/h) |
≤0.1 º/ h |
|
|
Angular Rate Range (°/s) |
-500~+500 º/s |
|
|
Bandwidth (Hz) |
≥200 |
|
|
Dimensions (mm) |
100*100*95 |
|
|
Weight (g) |
1100±50 (with accelerometer) |
|
|
Operating Temperature (°C) |
-45~+65 |
|
|
Quartz Accelerometer |
||
|
Range (g) |
≥±30 |
|
|
SF Temp Coeff (ppm/°C) |
≤60 |
|
|
SF Monthly Stability (ppm) |
≤60 |
|
|
Bias (mg) |
≤±7 |
|
|
Bias Temp Coeff (μg/°C) |
≤60 |
|
|
Bias Monthly Stability (μg) |
≤60 |
|
|
2nd-Order Nonlinearity (μg/g²) |
≤60 |
|
|
Mounting Angle (") |
≤200 |
|
|
Appearance |
No scratches, cracks, or corrosion |
|
Mechanical Dimensions Diagram
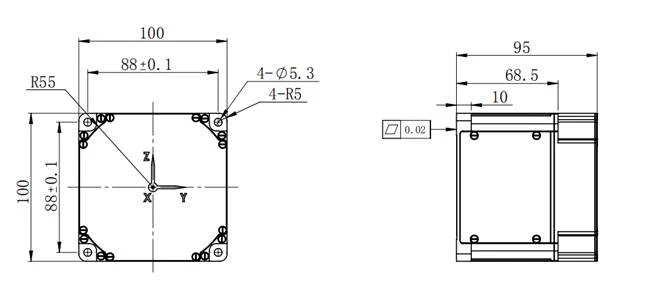
Introduction
Fiber optic gyro, as a new type of all-solid-state gyro, has the advantages of fast startup, wide measurement range and high reliability. Among them, F3X100-IMU type fiber optic gyro inertia set is designed for the needs of medium and low precision application background, adopting three-axis shared technology design, low cost and stable performance; the structure adopts the integrated package of optical circuit and circuit, simple structure, easy installation, and it can be applied in the system of navigation and guidance, attitude measurement and control of small missiles, guided bombs, and so on.
1.1 Application
This instruction manual only applies to the F3X100-IMU type product, and contains performance specifications, technical conditions, external dimensions, and installation and use. Among them, the technical conditions include the product's environmental range, electrical performance, and physical characteristics.
1.2 Main Parameters
|
Main parameters |
Index |
|
|
Type |
H |
M |
|
Bias Repeatability at Room Temperature (By times, by days) (º/h) |
≤0.05 |
≤0.1 |
|
Bias stability at Constant Temperature (º/ h) |
≤0.05 |
≤0.1 |
|
Scale Factor Repeatability at Room Temperature (ppm) |
≤20 |
≤20 |
|
Scale Factor Asymmetry at Constant Temperature (ppm) |
≤20 |
≤20 |
|
Scale Factor Nonlinearity at Constant Temperature (ppm) |
≤30 |
≤30 |
|
Threshold (º/h) |
≤0.1 º/h |
|
|
Angular Rate Range (º/s) |
-500 to +500 º/s |
|
|
Bandwidth (Hz) |
≥200 |
|
|
Dimensions (mm) |
100*100*95 |
|
|
Weight (g) |
1100±50 (with accelerometer) |
|
|
Operating Temperature (°C) |
-45 to +65 |
|
Quartz Accelerometer Parameters
|
No |
Item |
Technical Requirement |
|
1 |
Range (g) |
≥±30 |
|
2 |
Scale Factor Temperature Coefficient (ppm /°C) |
≤60 |
|
3 |
Scale Factor Monthly Stability (ppm) |
≤60 |
|
4 |
Bias (mg) |
≤±7 |
|
5 |
Bias Temperature Coefficient (μg /°C) |
≤60 |
|
6 |
Bias Monthly Stability (μg) |
≤60 |
|
7 |
Second-order Nonlinear Coefficient (μg /g2) |
≤60 |
|
8 |
Mounting angle (") |
≤200 |
|
9 |
Outlook |
No scratch No crack No corrosion |
1.2.2 Mechanical testing
1.2.2.1 Sinusoidal Scanning Vibration
The gyro is fixed on the vibration table through the fixture according to the direction of vibration, and the gyroscope carries out sinusoidal scanning in 3 directions, corresponding to the X-axis, Y-axis, and Z-axis directions, respectively. Vibration steps; vibration table plus excitation, to the gyroscope power, after a certain period of warm-up (gyro start-up time), test the output value of the gyroscope, about 5min; sinusoidal vibration. Vibration conditions: 20Hz-2000Hz, scanning time 5min, amplitude 4.2g. vibration process, record the gyroscope output.
Random Vibration
Vibration Frequency: 20Hz~2000Hz
Vibration Time: 5min for each axis
Vibration Direction: X, Y, Z axis
Vibration Spectrum: see Figure
Index requirements:
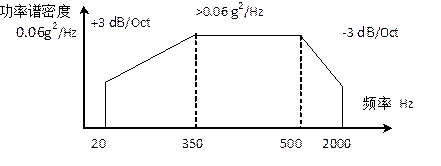
Fiber optic gyro shall be no resonance with sinusoidal scanning in the range of 20 HZ to 2000 Hz;
Random vibration: the absolute value of the bias in the vibration and the average bias before and after the vibration shall be less than 0.05º/h.
1.2.2.2 Mechanical shocks are as required by Table 2.
Table 2 Impact test conditions
|
Peak Acceleration (g) |
30 |
|
Duration (ms) |
11 |
|
Times of Impacts |
3 times in each direction |
|
Waveform |
half-sine wave |
|
Directions |
X, Y, Z |
|
Note: The interval between two impacts is not less than 1.5s. |
Impact process, the product should be able to work normally after mechanical impacts in the state of electricity, the bias should be less than 0.05º/h before and after the impact.
2 Communication protocols
2.1 IMU Data Transmission Protocol
Baud rate: 460800, no parity bit, 1 stop bit
Transmission frequency: 400Hz
Send Data Protocol:
|
Bits |
Name |
Unit |
Value |
Conversion |
Type |
|
0 |
Frame header byte 1 |
0xAA |
uchar |
||
|
1 |
Frame header byte 2 |
0xAA |
uchar |
||
|
2 |
Data Transmission Count |
1~200 |
uchar |
||
|
3 |
self-checking byte |
255 |
uchar |
||
|
4~7 |
X-axis gyro |
32bit low in front and high in back |
signed int32 |
||
|
8~11 |
Y-axis gyro |
32bit low in front and high in back |
signed int32 |
||
|
12~15 |
Z-axis gyro |
32bit low in front and high in back |
signed int32 |
||
|
16~19 |
X-axis plus table |
32bit low in front and high in back |
signed int32 |
||
|
20~23 |
Y-axis plus table |
32bit low in front and high in back |
signed int32 |
||
|
24~27 |
Z-axis plus table |
32bit low in front and high in back |
signed int32 |
||
|
28,29 |
X-axis gyro temperature |
16bit low in front high in back |
1/16 |
signed int16 |
|
|
30 |
checksum |
4~29-byte dissimilarity and |
uchar |
||
|
31 |
end of frame |
0xBB |
uchar |
3 Connecting Definition
The gyroscope electrical interface uses a J30-15ZK connector, and the nodes are defined in Table 4.
|
F3X100-IMU/INS Output Definition |
||
|
J30J-15ZK |
Definition |
Note |
|
5, 13 |
Power +24V |
Inertia Combination Power Supply |
|
6, 7 |
Power +24V (ground) |
|
|
1 |
Serial Port Transmit 3+ |
Serial Port |
|
2 |
Serial Port Transmit 3- |
|
|
3 |
Serial Port Receive 3+ |
|
|
4 |
Serial Port Receive 3- |
|
|
11 |
Serial Port Transmit 2+ |
IMU Data Output Serial Port |
|
12 |
Serial Port Transmit 2- |
|
|
14 |
Serial Port Transmit 1+ |
Debugging Serial Ports |
|
15 |
Serial Port Transmit 1- |
|
|
9 |
Serial Port Receive 1+ |
|
|
10 |
Serial Port Receive 1- |
|
Dimensions
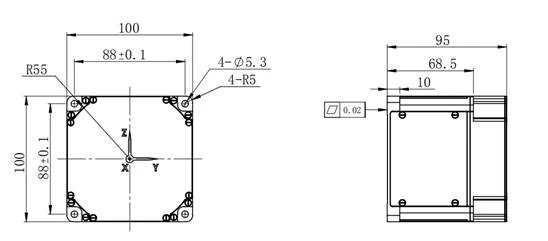
Figure 2 F3X100-IMU Dimension
Hot Tags: f3x100 three-axis fog imu, China f3x100 three-axis fog imu manufacturers, factory