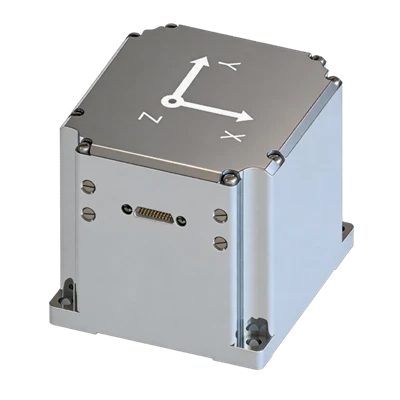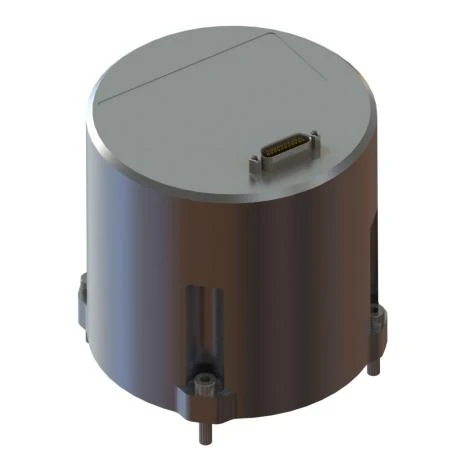
FSU307 Fiber Optic Inertial Measurement Unit
Full-temp calibration
Harsh-environment resistant
Vibration & EMI resistant
Online upgrade & self-calib
Description
Key Features
- Lightweight, domestic
- Rich interfaces
- 10 W low power
- Full-temp calibration
- Harsh-environment resistant
- Vibration & EMI resistant
- Online upgrade & self-calib
Applications
- Mobile survey & attitude
- Unmanned systems (ground/marine/UW)
- Surveying & north-finding
- Stabilized platforms
- SATCOM-on-the-move
- Autonomous driving & munitions
Product Introduction
Company's FSU307 fiber optic inertial measurement unit is a high-reliability, cost-effective navigation system for aircraft, UGVs, USVs, UAVs, and similar platforms. Inheriting a modular design philosophy, it integrates high-precision silicon photonic gyroscopes and MEMS accelerometers. Beyond IMU applications, its software is configurable for transfer alignment, integrated navigation, pure INS, and AHRS modes, adapting to diverse inertial navigation requirements to meet varied user needs.
Unique Technology
Company is a high-tech enterprise with full closed-loop capabilities from fiber winding equipment and coils to FOGs, fiber/MEMS inertial products, IMU circuits, software, and test equipment. End-to-end process control improves quality and reduces costs. Operating under ISO9001 with strict processes, it ensures product reliability and consistency.
FSU307 Fiber Inertial Measurement Unit Performance Specifications
|
Parameter |
Specifications |
|
Fiber OpticGyro |
|
|
Range (°/s) |
±500 |
|
Bias (°/h) |
1 |
|
Bias Stability (°/h, 10s avg.) |
0.5 |
|
Bias Instability (°/h, Allan) |
0.05 |
|
Bias Repeatability (°/h, 6 cycles) |
0.5 |
|
ARW (°/√h) |
0.025 |
|
Scale Nonlinearity (ppm) |
100 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200 |
|
MEMSAccelerometer |
|
|
Range (g) |
±30 |
|
FT Bias (mg, 3σ) |
≤0.5 |
|
Bias Stability (μg, 10s avg.) |
≤10 |
|
Bias Instability (μg, Allan, typ.) |
≤3 |
|
Bias Repeatability (μg) |
≤10 |
|
Velocity Random Walk (m/s/√h) |
≤0.01 |
|
Scale Nonlinearity (ppm, ±1g) |
≤100 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200 |
|
Electrical/Mechanical Interface |
|
|
Input Voltage (V DC) |
5 |
|
Power Consumption (W) |
≤10 |
|
Dimensions (mm) |
88.9×89.55 |
|
Unit Weight (kg) |
≤0.5 |
|
Operating Environment |
|
|
Operating Temperature (°C) |
-40 ~ +70 |
|
Storage Temperature (°C) |
-55 ~ +85 |
|
Vibration (g) |
6 @ 20~2000 Hz |
|
Shock (g) |
100 , 11 ms |
|
Reliability/Suitability |
|
|
MTBF/MTTR (h) |
10000 / 0.5 |
|
Maintenance |
BIT 95% |
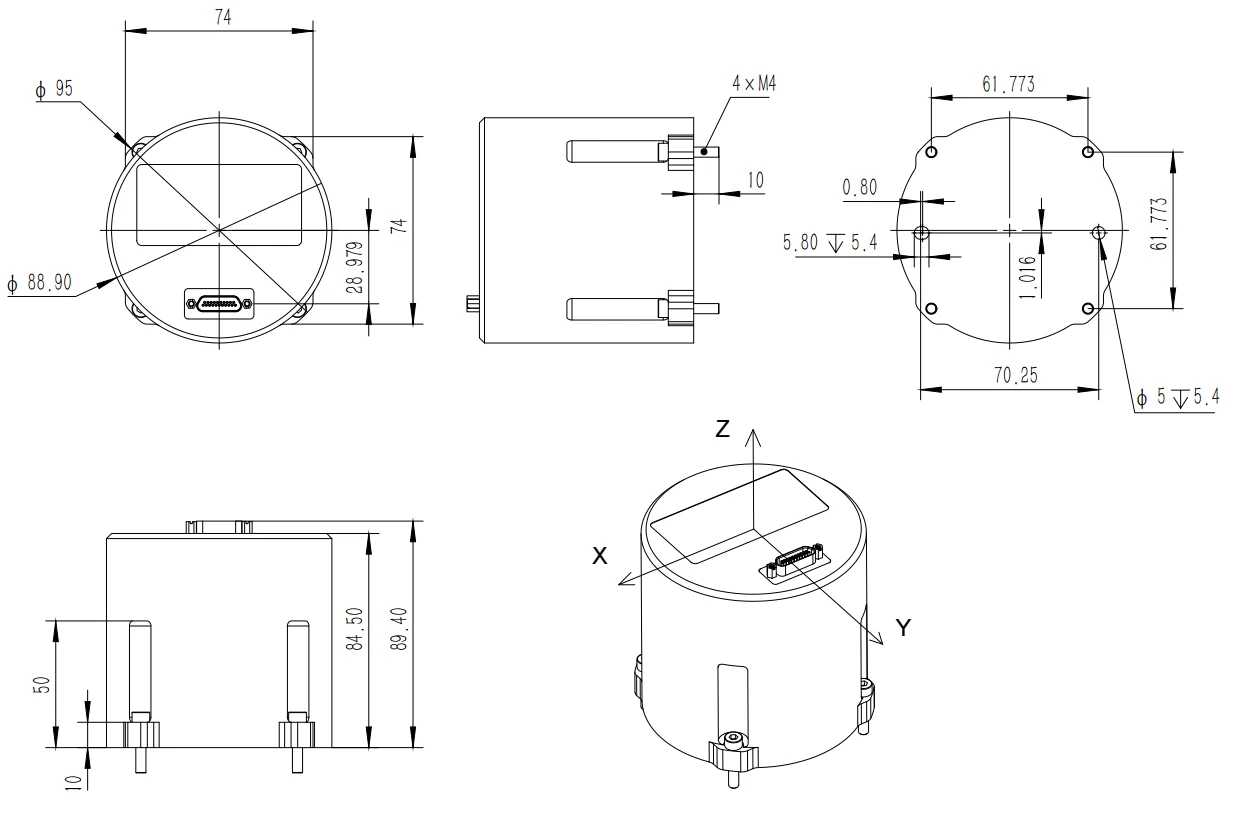
Mechanical Dimensions Diagram
Device Description
Product Overview
FSU307 fiber optic IMU is a high-reliability, cost-effective navigation system widely used in navigation, control, and measurement for aircraft, UGVs, USVs, and UAVs.
The IMU inherits a modular design philosophy, employing high-precision silicon photonic gyroscopes and high-precision MEMS accelerometers. Beyond standalone IMU operation, it supports configurable software modes including transfer alignment, integrated navigation, pure INS computation, and AHRS to maximize compatibility with diverse applications.
Product Composition
FSU307 fiber optic IMU consists of a three-axis silicon photonic gyroscope, high-precision MEMS accelerometer, signal processing circuit, navigation software, mechanical components, and test cable. Key components:
Table 1 IMU Main Components
|
No. |
CompositionComponent |
Qty |
Model |
Remarks |
|
1 |
High-Precision INS |
1 |
FSU307 |
|
|
2 |
Connector Plug |
1 |
J20JD-21TJL |
Male |
Key Features
- Key features of FSU307 fiber optic IMU:
- Domestic core components, high performance, modular, lightweight
- Rich interfaces
- 10 W steady-state power
- Full-temp calibration, -40°C to +70°C
- Mechanical environment resistant
- Vibration, shock, and EMI resistant
- Online firmware upgrade and installation error compensation
Applications
- Primary applications of FSU307 fiber optic IMU:
- Mobile position and attitude reference
- UGVs, USVs/UUVs
- Surveying
- Stabilized platforms
- Underwater vehicles
- SATCOM on the move
- Intelligent driving
- Munition guidance
- Intelligent mining north-finding
Technical Parameters
System Specifications
Table 2 FSU307 Fiber Optic IMU Performance Specifications
|
Fiber Optic Gyroscope |
|
|
Range (°/s) |
±500 |
|
Bias (°/h) |
1 |
|
Bias Stability (°/h, 10s avg.) |
0.5 |
|
Bias Instability (°/h, Allan) |
0.05 |
|
Bias Repeatability (°/h, 6 cycles) |
0.5 |
|
ARW (°/√h) |
0.025 |
|
Scale Nonlinearity (ppm) |
100 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200 |
|
MEMS Accelerometer |
|
|
Range (g) |
±30 |
|
FT Bias (mg,3σ) |
≤0.5 |
|
Bias Stability (μg,10savg.) |
≤10 |
|
Bias Instability (μg,allan,typ) |
≤3 |
|
Bias Repeatability (ug) |
≤10 |
|
VRW (m/s/√h) |
≤0.01 |
|
Scale Nonlinearity (ppm,±1g) |
≤100 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
Electrical/Mechanical Interface |
|
|
Input Voltage (V DC) |
5 |
|
Power Consumption (W) |
≤10 |
|
Dimensions (mm) |
88.9×89.55 |
|
Unit Weight (kg) |
≤0.5 |
|
Operating Environment |
|
|
Operating Temperature (°C) |
-40~ +70 |
|
Storage Temperature (°C) |
-55~ +85 |
|
Vibration ( g) |
6 @ 20~2000 Hz |
|
Shock (g) |
100 , 11 ms |
|
Reliability/Suitability |
|
|
MTBF/MTTR (h) |
10000 / 0.5 |
|
Maintenance |
BIT 95% |
Mechanical Interface
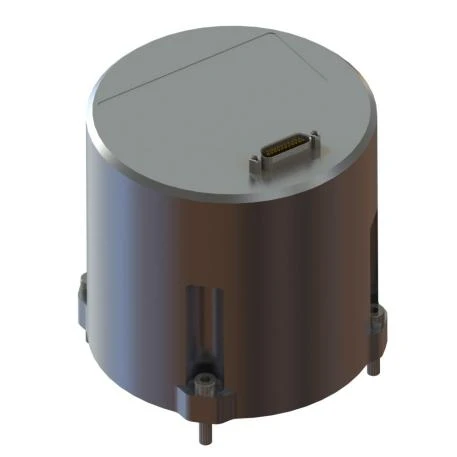
Mechanical interface of FSU307 fiber optic IMU is shown below:
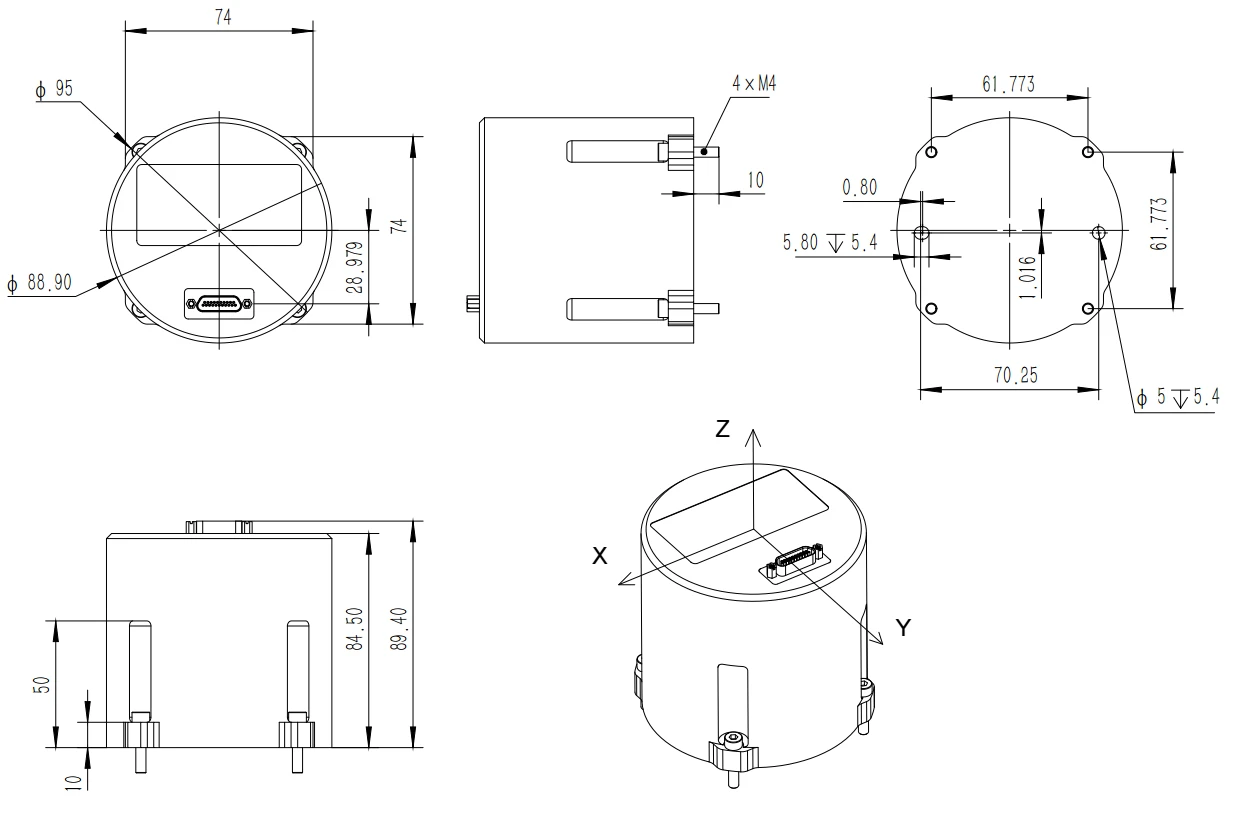
Fig. 1 FSU307 Fiber Optic Inertial Measurement UnitMechanical InterfaceFig.
Electrical Interface
FSU307 IMU uses a J30JM-21ZKP connector, mating with J30J-21TJL plug. The connector pinout is defined as follows:
Table 3 FSU307 Fiber Optic IMU Connector Pinout
|
Pin |
PinDefinition |
DB9 Definition |
Interface |
FunctionDescription |
|
1 |
Vin+ |
Red AlligatorVin+ |
Input Range+5V |
System Power Input |
|
12 |
||||
|
2 |
GND |
Black Alligator GND |
GND |
System Power Ground |
|
13 |
||||
|
4 |
Reserved |
/ |
/ |
|
|
15 |
Reserved |
/ |
||
|
16 |
RS422_RX+ |
DB9-M1-1 |
M1:Isolated RS422 |
Data output, system configUpgrade |
|
5 |
RS422_RX- |
DB9-M1-2 |
||
|
6 |
RS422_TX+ |
DB9-M1-3 |
||
|
17 |
RS422_TX- |
DB9-M1-4 |
||
|
14 |
GGND |
DB9-M1-5 |
||
|
7 |
Reserved |
|||
|
19 |
Reserved |
|||
|
18 |
Reserved |
|||
|
21 |
RS232_TXD2 |
DB9-M3-2 |
M3: Isolated RS232 |
NavigationData output |
|
9 |
RS232_RXD2 |
DB9-M3-3 |
||
|
10 |
GGND |
DB9-M3-5 |
||
|
8 |
PPS_IN |
Pigtail |
TTL Level |
|
|
11 |
GGND |
Pigtail |
GND |
Isolated Ground |
|
20 |
TOV_OUT |
Pigtail |
||
|
3 |
GGND |
Pigtail |
GND |
Isolated Ground |
Data Protocol
The general IMU protocol outputs data in timed broadcast mode at 200 Hz, 40 bytes per frame, 460800 bps, 1 start bit, 8 data bits, 1 stop bit, no parity, LSB first. Baud rate and output rate are configurable.
Table 4 FSU307 Fiber Optic IMU Protocol
|
No. |
Offset |
Byte Count |
Content |
Scale |
Range |
Unit |
Remarks |
|
1 |
0 |
1 |
0x55 |
1 |
|
|
Header |
|
2 |
1 |
1 |
0xAA |
1 |
|
|
Header |
|
3 |
2 |
1 |
36 |
1 |
|
|
Data Length |
|
4 |
3 |
4 |
PCnum |
1 |
|
|
1 ms Counter |
|
5 |
7 |
4 |
Angular Rate X |
0.000001 |
[-1000,1000] |
°/s |
|
|
6 |
11 |
4 |
Angular Rate Y |
0.000001 |
[-1000,1000] |
°/s |
|
|
7 |
15 |
4 |
Angular Rate Z |
0.000001 |
[-1000,1000] |
°/s |
|
|
8 |
19 |
4 |
Accel X |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
9 |
23 |
4 |
Accel Y |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
10 |
27 |
4 |
Accel Z |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
11 |
31 |
2 |
Temperature |
0.008 |
[-120,120] |
℃ |
|
|
12 |
33 |
2 |
Reserved |
|
|
|
|
|
13 |
35 |
4 |
Reserved |
|
|
|
|
|
14 |
39 |
1 |
Checksum |
1 |
[0, 255] |
|
Lower 8 bits of bytes 2-38 sum |
Hot Tags: fsu307 fiber optic inertial measurement unit, China fsu307 fiber optic inertial measurement unit manufacturers, factory