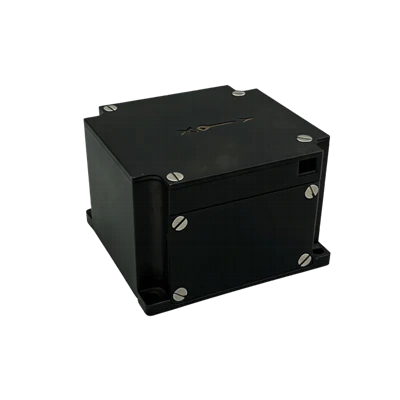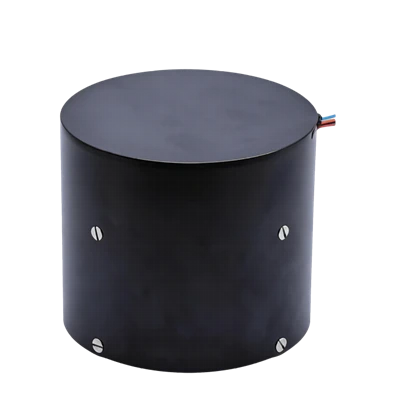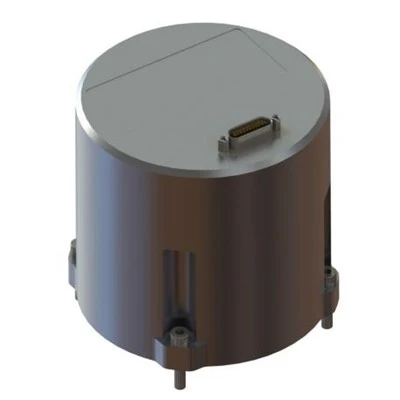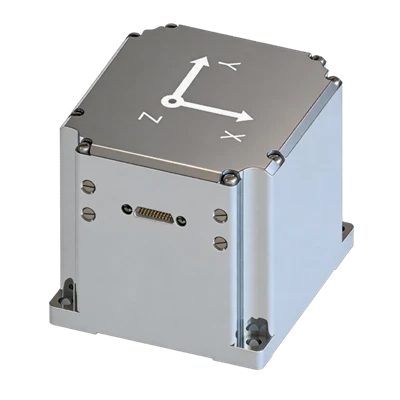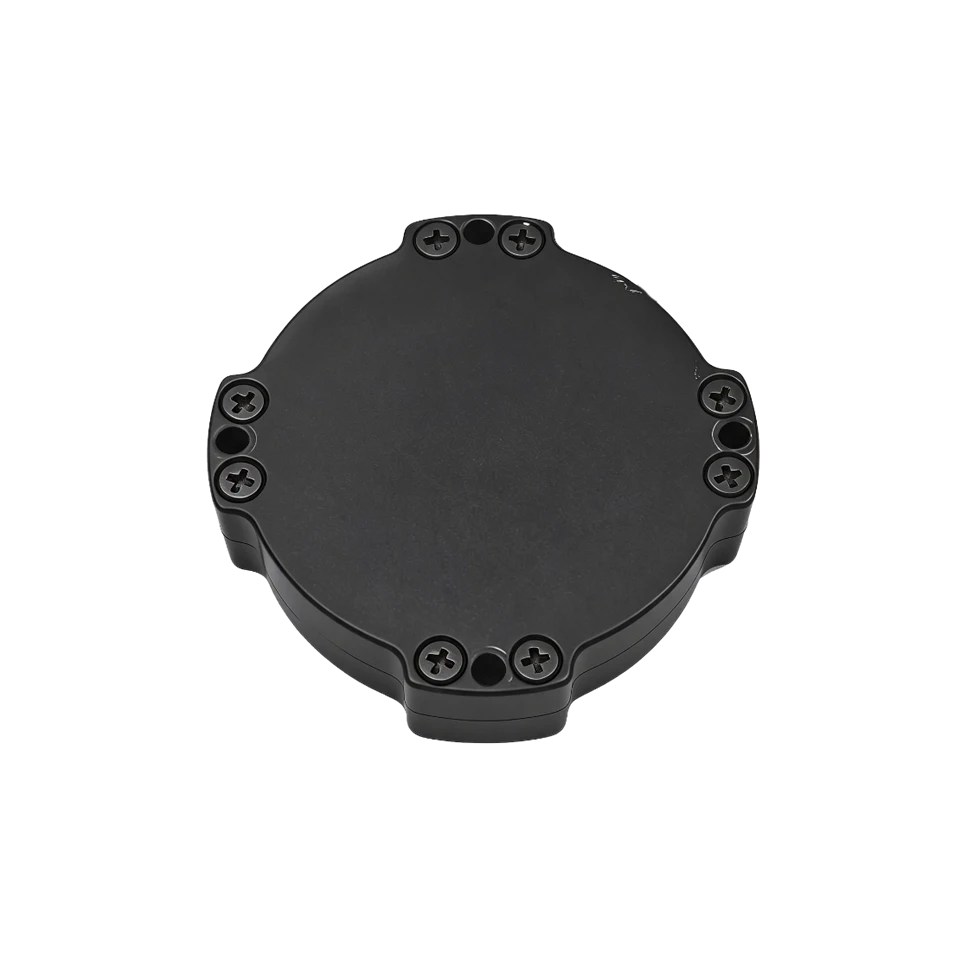
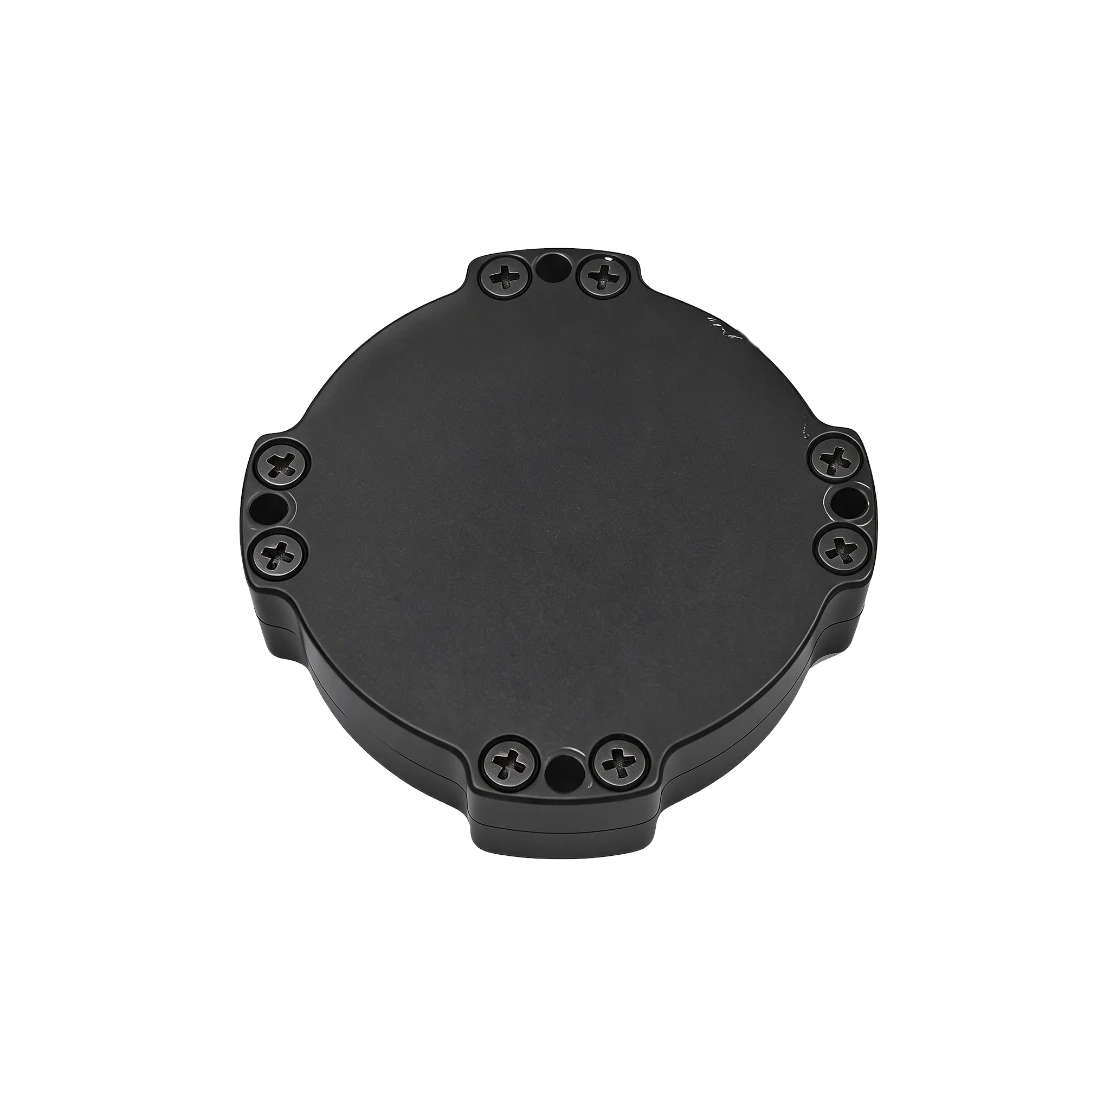
MNU107 MEMS Inertial Measurement Unit
Multi-sensor redundancy and fault-tolerant design
High performance, compact size, low power consumption
-40°C to +80°C full-temperature calibration and compensation
Description
Main Features
- Multi-sensor redundancy and fault-tolerant design
- High performance, compact size, low power consumption
- -40°C to +80°C full-temperature calibration and compensation
- 1kHzHigh-speed sampling
- Resistance to harsh mechanical environments
- Software online upgrade capability
Applications
- High-overload missile-borne application
- Flight control
Product Introduction
MNU107 is a highly reliable and cost-effective three-axis MEMS inertial sensor, which can be widely used in navigation, control, and measurement fields represented by inertial navigation.
MNU107 integrates high-performance MEMS gyroscopes and MEMS accelerometers. The system internally performs compensation for bias, Scale Factor, non-orthogonality errors, and acceleration-related terms across full temperature parameters, maintaining high measurement accuracy over extended periods.
adopts strict processes to ensure the reliability and consistency of product performance.
MNU107 MEMS Inertial Measurement Unit
|
MEMS Gyroscope |
|
|
Range (°/s) |
X-axis: ±5400°/s ,Y/Z-axis: ±500°/s |
|
Bias @ Full temp. (°/s, 3σ) |
≤360 |
|
Bias Stability (°/h, 10s smoothing) |
≤20 |
|
Bias Repeatability (°/h) |
≤20 |
|
Bias Instability (°/h, Allan, typ) |
≤5 |
|
Angular Random Walk (°/√h) |
≤0.8 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
MEMS Accelerometer |
|
|
Range (g) |
±20 |
|
Bias @ Full temp. (mg, 3σ) |
≤20 |
|
Bias Stability (μg, 10s smoothing) |
≤500 |
|
Bias Instability (μg, Allan, typ) |
≤100 |
|
Bias Repeatability (μg) |
≤500 |
|
Velocity Random Walk (m/s/√h) |
≤0.06 |
|
Scale Factor Nonlinearity (ppm, ±1g) |
≤300 |
|
Cross-Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
Electrical/Mechanical Interface |
|
|
Power Supply (V) |
5±0.2 |
|
Power (W) |
≤1 |
|
Startup Time (s) |
≤2 |
|
Communication interface |
RS-422 |
|
Update Rate (Hz) |
1000 |
|
Dimensions (mm×mm×mm) |
Ф55 × 15 |
|
Weight (g) |
≤60 |
|
Operating Environment |
|
|
Operating Temp. (°C) |
-40~80 |
|
Storage Temp. (°C) |
-55~85 |
|
Vibration (g, Rms) |
6.06,20~2000Hz |
|
Shock (g) |
15000/10ms |
Product Introduction
Product Overview
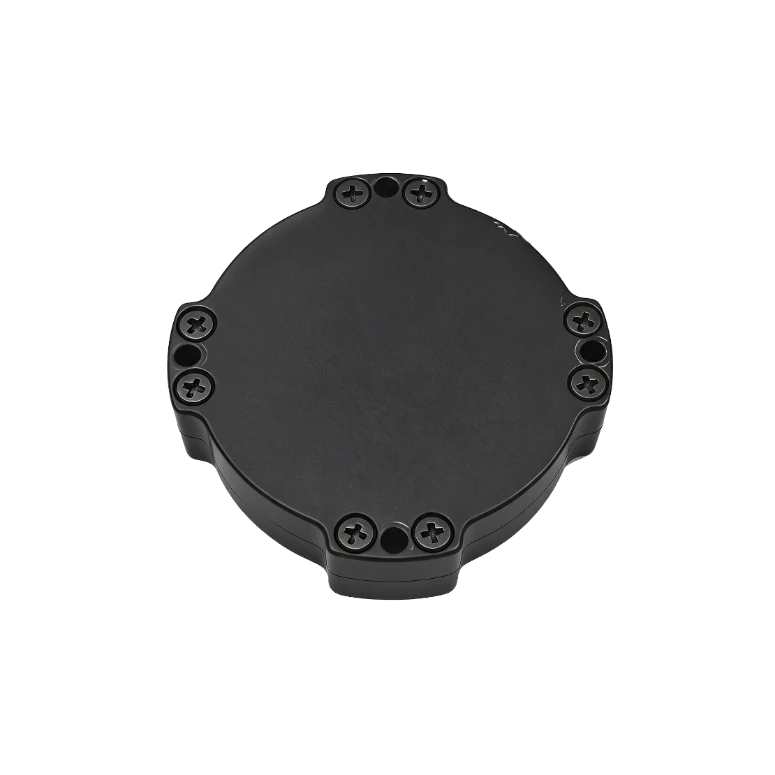
The MNU107 MEMS Inertial Measurement Unit is a highly reliable and cost-effective tri-axis MEMS inertial sensor, widely applicable in navigation, control, and measurement fields, with inertial navigation as a representative application.
The MNU107 MEMS Inertial Measurement Unit integrates high-performance MEMS gyroscopes and MEMS accelerometers within a standalone structure. The gyroscopes and accelerometers selected for this system represent the leading level of MEMS-process inertial devices. The tri-axis MEMS gyroscopes sense the angular motion of the carrier, and the tri-axis MEMS accelerometers sense the linear acceleration of the carrier. The system internally performs compensation for bias, scale factor, non-orthogonality error, and acceleration-related terms over the full temperature range, maintaining high measurement accuracy over extended periods.
Key Features
- Multi-sensor redundancy and fault tolerance design
- High performance, compact size, lightweight, low power consumption
- Full temperature calibration and compensation from -40 ℃ to +80 ℃
- 1k Hz high-speed sampling
- Harsh mechanical environment resistance
- Software online upgrade capability
Applications
- High-overload missile-borne application
- Flight Control
Technical Specifications
Table 1 MNU107 Inertial Measurement Unit Performance Specifications
|
Gyroscope |
|
|
Range (°/s) |
X-axis: ±5400°/s Y, Z-axis: ±500°/s |
|
Bias @ Full Temp. (°/s, 3σ) |
≤360 |
|
Bias Stability (°/h, 10s Smoothing) |
≤20 |
|
Bias Repeatability (°/h) |
≤20 |
|
Bias Instability (°/h, Allan, typ.) |
≤5 |
|
Angle Random Walk (°/√h) |
≤0.8 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Axis Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
Accelerometer |
|
|
Range (g) |
±20 |
|
Bias @ Full Temp. (mg, 3σ) |
≤20 |
|
Bias Stability (μg, 10s Smoothing) |
≤500 |
|
Bias Instability (μg, Allan, typ.) |
≤100 |
|
Bias Repeatability (μg) |
≤500 |
|
Velocity Random Walk (m/s/√h) |
≤0.06 |
|
Scale Factor Nonlinearity (ppm, ±1g) |
≤300 |
|
Cross-Axis Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
Electrical/Mechanical Interface |
|
|
Power Supply (V) |
5±0.2 |
|
Power Consumption (W) |
≤1 |
|
Startup Time (s) |
≤2 |
|
Communication Interface |
RS-422 |
|
Output Data Rate (Hz) |
1000 |
|
Dimensions (mm) |
Ф55 × 15 |
|
Weight (g) |
≤60 |
|
Operating Environment |
|
|
Operating Temperature (℃) |
-40~80 |
|
Storage Temperature (℃) |
-55~85 |
|
Vibration (g,Rms) |
6.06,20~2000HZ |
|
Shock (g) |
15000/10ms |
Technical Specifications
Mechanical Characteristics
MNU107 MEMS inertial measurement unit adopts high-strength aerospace aluminum alloy structure,structural integrity, providing high vibration and shock resistance The module adopts 4*M3 screw mounted. It's mechanical dimensions are shown in Figure 1:
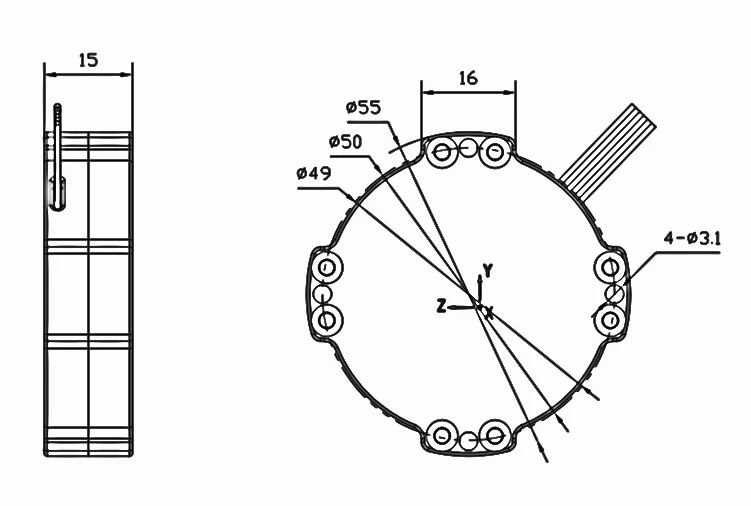
Figure 1 Mechanical Dimensions
Product Marking and Orientation
Product installation must ensure a fixed relationship between the product body coordinate system and the body coordinate system of the application object. The body coordinate system of the MEMS Inertial Measurement Unit is defined as follows:
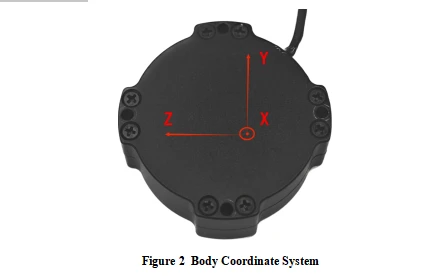
Interface Definition
The MEMS Inertial Measurement Unit provides one RS422 interface output, with functions distinguished by color-coded wires. The cable harness length is no less than 100mm, and the wire diameter is no less than 0.07mm2. The electrical interface is as follows:
Table 2 MNU107 Inertial Measurement Unit (IMU)Connector Pin Definition
|
Pin No. |
Color |
Definition |
Remarks |
|
1 |
Yellow |
R422A_R+ |
Communication |
|
2 |
Green |
R422A_R- |
|
|
3 |
Purple |
R422A_T+ |
|
|
4 |
Orange |
R422A_T- |
|
|
5 |
Red |
+5V |
Power Supply |
|
6 |
Black |
GND |
Communication Protocol
3.4.1 XDIMU-55AAProtocol
The XDIMU-55AA protocol features40 bytes per data frame,with periodic broadcast output, default output frequency1000Hz, default baud rate921600bps. The baud rate and output frequency of the communication protocol can be configured via the host computer. The data frame format is: 1 start bit, 8 data bits, 1 stop bit, no parity bit, little-endian byte order (low byte first, high byte second) (Little-Endian Mode, Intel Mode)
Table 3 MNU107 MEMS Inertial Measurement UnitXDIMU-55AAFormat
|
Pin No. |
Definition |
Remarks |
|
1 |
Frame Header |
55H |
|
2 |
Frame Header |
AAH |
|
3 |
Data Length |
N-4 |
|
4~N-1 |
Data |
|
|
N |
Checksum |
checksum |
|
Note: The checksum is the lower 8 bits of the cumulative sum of the data length and all bytes in the data packet. |
||
Table 4 MNU107 MEMS Inertial Measurement UnitXDIMU-55AACommunication Content
|
No. |
Byte Start |
Byte Count |
Data Type |
Content |
Equivalent |
Range |
Unit |
Remarks |
|
1 |
0 |
1 |
UINT8 |
0x55 |
1 |
Frame Header |
||
|
2 |
1 |
1 |
UINT8 |
0xAA |
1 |
Frame Header |
||
|
3 |
2 |
1 |
UINT8 |
36 |
1 |
Data Length |
||
|
4 |
3 |
4 |
UINT32 |
PCnum |
1 |
1ms Counter Value |
||
|
5 |
7 |
4 |
INT32 |
Angular Rate X |
0.000003 |
[-6000,6000] |
°/s |
|
|
6 |
11 |
4 |
INT32 |
Angular Rate Y |
0.000003 |
[-6000,6000] |
°/s |
|
|
7 |
15 |
4 |
INT32 |
Angular Rate Z |
0.000003 |
[-6000,6000] |
°/s |
|
|
8 |
19 |
4 |
INT32 |
Acceleration X |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
9 |
23 |
4 |
INT32 |
Acceleration Y |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
10 |
27 |
4 |
INT32 |
Acceleration Z |
0.000001 |
[-40g,40g] |
m/s2 |
|
|
11 |
31 |
2 |
short |
System Temperature |
0.008 |
[-120,120] |
℃ |
|
|
12 |
33 |
2 |
short |
Geomagnetic X |
1 |
LSB |
||
|
13 |
35 |
2 |
short |
Geomagnetic Y |
1 |
LSB |
||
|
14 |
37 |
2 |
short |
Geomagnetic Z |
1 |
LSB |
||
|
15 |
39 |
1 |
UINT8 |
Checksum |
1 |
[0,255] |
Lower 8 bits of byte cumulative sum (index 2 to 38) |
Precautions
- Pay attention to the product electrical interface definition. During use, strictly follow the terminal pin configuration to avoid incorrect connections;
- The product is a precision measurement device. During handling, avoid subjecting it to shock, collision, or other conditions exceeding the product's tolerance range;
- Product installation significantly affects angular velocity measurement. To avoid introducing mounting errors, the mounting surface must have good flatness;
- To ensure measurement accuracy, the product must be mounted securely and firmly to avoid measurement errors caused by loosening;
- During product installation and use, ESD (Electrostatic Discharge) protection should be observed. It is recommended to wear an ESD wrist strap;
- Please strictly follow the requirements of this manual for operation. Ensure that the external environment matches the usage requirements. In case of issues, do not open the product cover or modify the internal structure. If any problems arise, please contact our technical support team in a timely manner
Hot Tags: mnu107 mems inertial measurement unit, China mnu107 mems inertial measurement unit manufacturers, factory