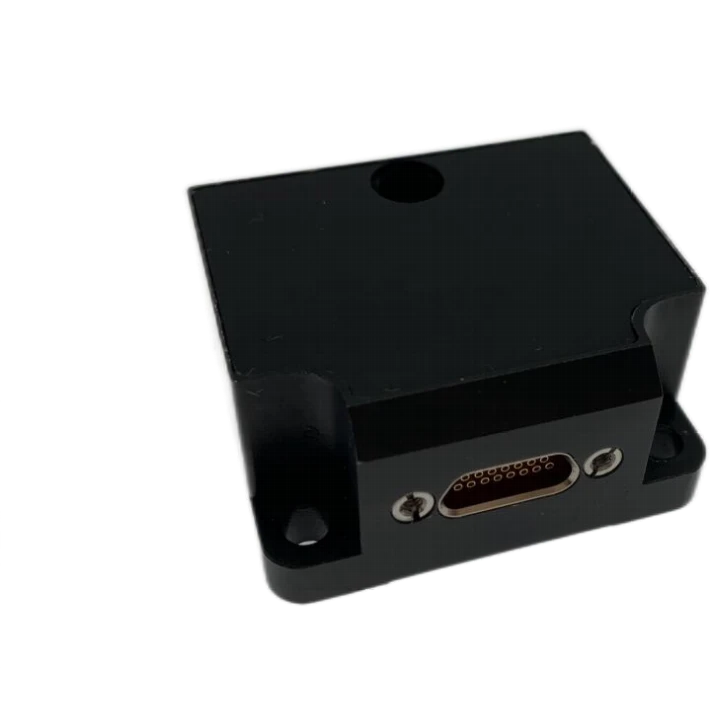
MTG200 MEMS Gyro
100% domestically sourced components
High performance, compact outline, light weight, low power consumption
2 kHz high-speed sampling
Description
Main Features
- 100% domestically sourced components
- High performance, compact outline, light weight, low power consumption
- 2 kHz high-speed sampling
- Excellent resistance to severe mechanical environments
- Support for in-field software upgrade
Application Fields
 Servo stabilization systems
 Optoelectronic pods
 Satellite attitude control
Product Overview
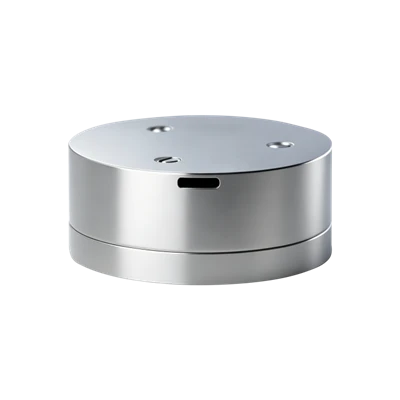
The MTG200 series MEMS three-axis gyro assembly is a high-reliability, cost-effective three-axis gyro module, serving as the control sensor for various stabilization platforms. It has been mass-applied in optoelectronic pods and low-to-medium Earth orbit satellites. All electronic components inside the system are fully domestically sourced.Featuring compact size, light weight, low power consumption, and a simple interface, it offers exceptional cost performance. Based on proven designs with engineering optimizations for mass production, it delivers outstanding value across inertial measurement fields.
Unique Technology
The MTG200 series MEMS three-axis gyro assembly is a high-reliability, cost-effective three-axis gyro module, serving as the control sensor for various stabilization platforms. It has been mass-applied in optoelectronic pods and low-to-medium Earth orbit satellites. All electronic components inside the system are fully domestically sourced.Featuring compact size, light weight, low power consumption, and a simple interface, it offers exceptional cost performance. Based on proven designs with engineering optimizations for mass production, it delivers outstanding value across inertial measurement fields.
MTG200 Tri-axis MEMS Gyro Combination
MTG200 Tri-axis MEMS Gyro Combination Performance Parameters
|
Parameter |
Technical Index |
|
Gyroscope |
|
|
Measurement Range (°/s) |
±500 |
|
Full-Temperature Bias (°/h, 3σ) |
≤30 |
|
Bias Stability (°/h, 10s smoothing window) |
≤2 |
|
Bias Instability (°/h, Allan variance, typical) |
0.1 |
|
Bias Repeatability (°/h) |
≤1 |
|
Angular Random Walk (°/√h) |
≤0.1 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Coupling Error (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200 Hz |
|
Electrical & Mechanical Interfaces |
|
|
Power Supply Voltage (V) |
5~12 (ripple ≤100 mV) |
|
Steady-State Power Consumption (W) |
≤1.5 |
|
Startup Time (s) |
≤2 |
|
Maximum Data Update Rate (Hz) |
2000 |
|
Overall Dimension (mm×mm×mm) |
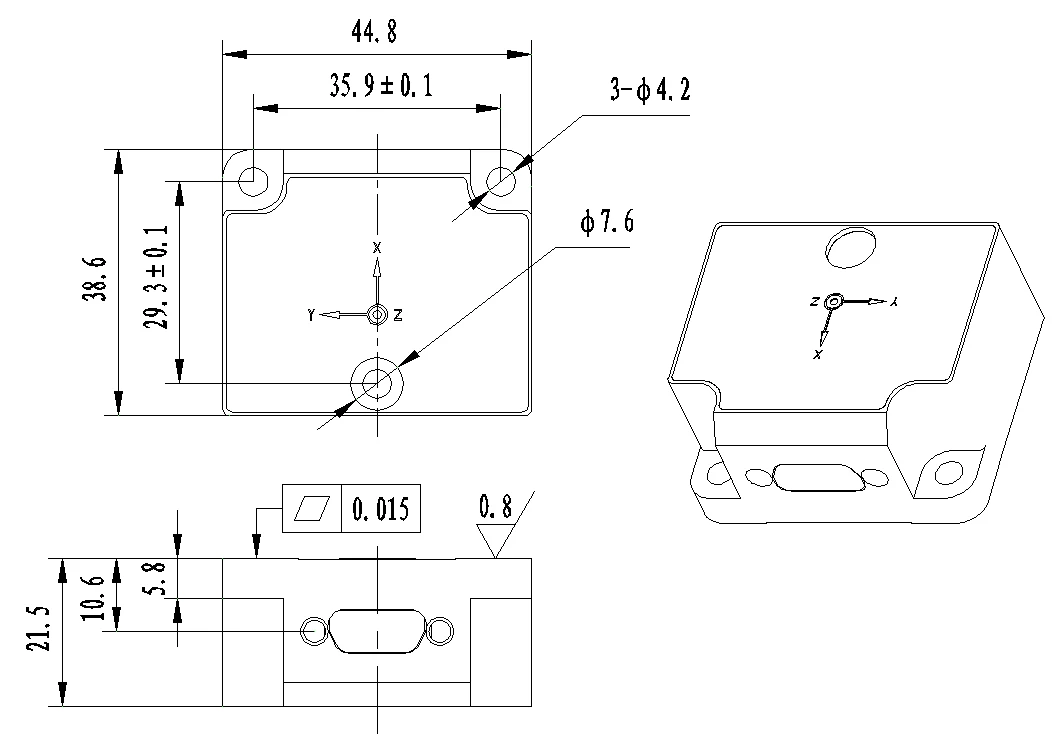
44.8×38.6×21.5 |
|
Weight (g) |
50±5 |
|
Operating Environment |
|
|
Operating Temperature (℃) |
-40 ~ 80 |
|
Storage Temperature (℃) |
-55 ~ 85 |
|
Vibration (g, RMS) |
20~2000 Hz, 6.06 |
|
Shock (g, half-sine pulse) |
500 / 1 ms |
Dimensional Drawing
Product Introduction
Product Brief
The MTG200 series MEMS three-axis gyro assembly is a high-reliability, cost-effective three-axis gyro module, serving as the control sensor for various stabilization platforms. It has been mass-applied in optoelectronic pods and low-to-medium Earth orbit satellites. All electronic components inside the system are fully domestically sourced.
Product Features
100% domestically sourced components
High performance, compact outline, light weight, low power consumption
Full-temperature calibration and compensation ranging from -40℃ to +80℃
2 kHz high-speed sampling
Excellent resistance to severe mechanical environments
Support for in-field software upgrade
Application Fields
- Servo stabilization systems
- Optoelectronic pods
- Satellite attitude control
Technical Parameters
Table 1 Performance Parameters of MTG200 Three-Axis Gyro Assembly
|
Parameter |
Technical Index |
|
Gyroscope |
|
|
Measurement Range (°/s) |
±500 |
|
Full-Temperature Bias (°/h, 3σ) |
≤30 |
|
Bias Stability (°/h, 10s smoothing window) |
≤2 |
|
Bias Instability (°/h, Allan variance, typical) |
0.1 |
|
Bias Repeatability (°/h) |
≤1 |
|
Angular Random Walk (°/√h) |
≤0.1 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Coupling Error (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200 Hz |
|
Electrical & Mechanical Interfaces |
|
|
Power Supply Voltage (V) |
5~12 (ripple ≤100 mV) |
|
Steady-State Power Consumption (W) |
≤1.5 |
|
Startup Time (s) |
≤2 |
|
Maximum Data Update Rate (Hz) |
2000 |
|
Overall Dimension (mm×mm×mm) |
44.8×38.6×21.5 |
|
Weight (g) |
50±5 |
|
Operating Environment |
|
|
Operating Temperature (℃) |
-40 ~ 80 |
|
Storage Temperature (℃) |
-55 ~ 85 |
|
Vibration (g, RMS) |
20~2000 Hz, 6.06 |
|
Shock (g, half-sine pulse) |
500 / 1 ms |
Technical Specifications
Structural Characteristics
The MTG200 three-axis gyro assembly adopts an aluminum alloy mechanical housing, featuring light weight, high structural strength, and outstanding vibration & shock resistance. The outline dimensions of the unit are shown in Figure 1, and the unit is fixed with 3 M4 screws.
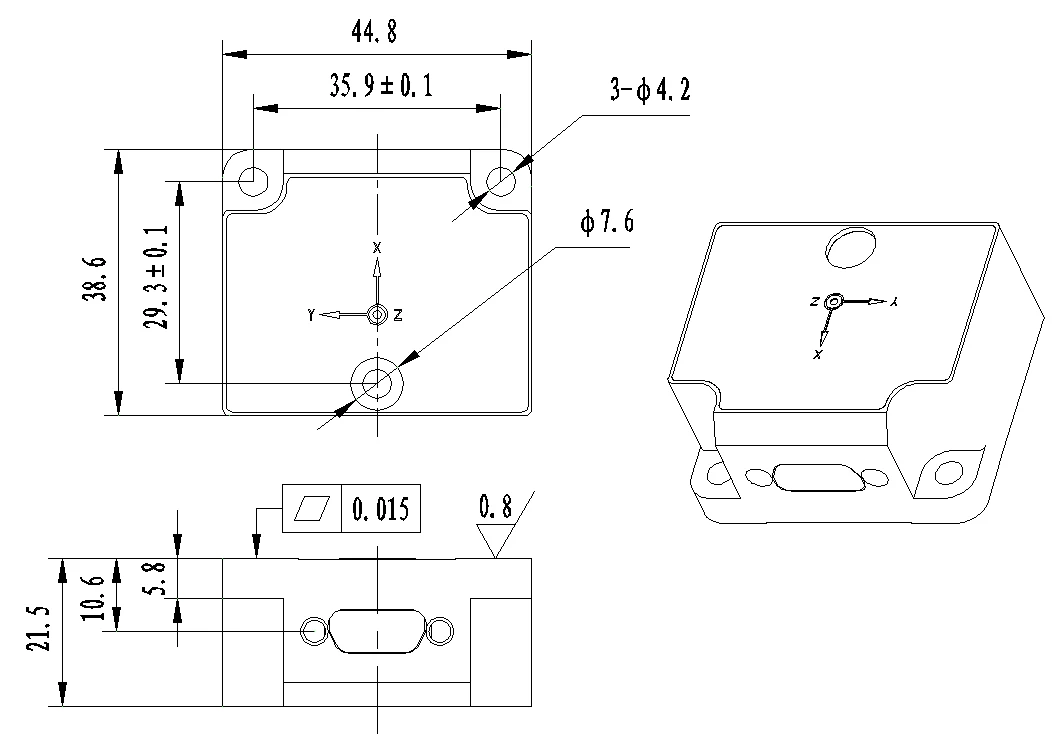
Figure 1 Outline Dimensions
Product Marking and Coordinate Polarity
During installation, the carrier coordinate system of the product shall maintain a fixed geometric relationship with the carrier coordinate system of the host equipment. The carrier coordinate system definition of the MTG200 MEMS three-axis gyro assembly is specified as follows.
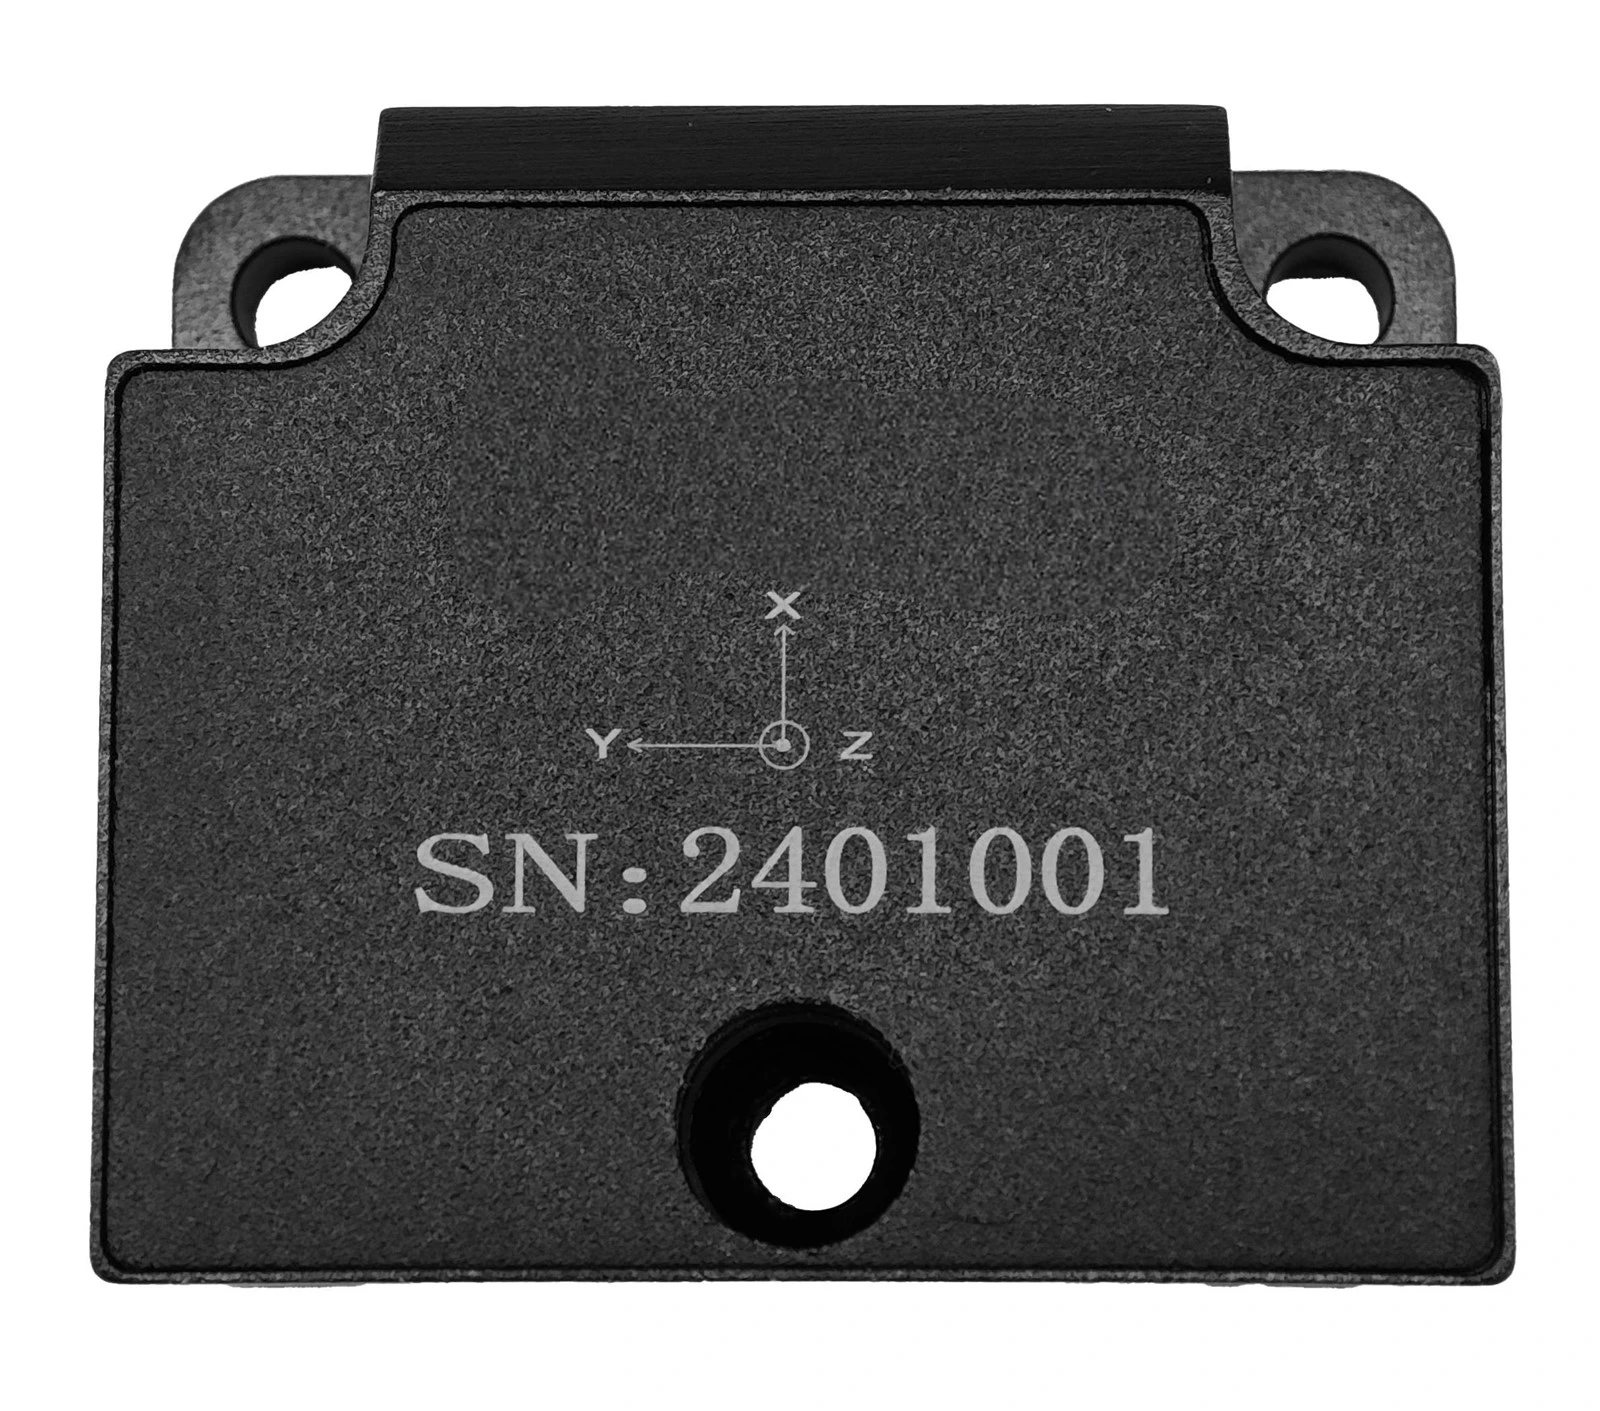
Figure 2 Product Coordinate System
Pin Assignment
The external output connector of the MTG200 three-axis gyro assembly is J30J-15ZK (mating connector: J30J-15TJL), which provides power supply and external communication for the unit. The pin definitions of the connector are listed in Table 2.
Table 2 External Pin Assignment of MTG200 Three-Axis Gyro Assembly Connector
|
Pin No. |
Definition |
Remarks |
|
8 |
POWER_IN |
5~12 V power input |
|
15 |
GND |
Power ground |
|
10 |
RS422 R+ |
RS422 receive positive differential line |
|
2 |
RS422 R- |
RS422 receive negative differential line |
|
9 |
RS422 T+ |
RS422 transmit positive differential line |
|
1 |
RS422 T- |
RS422 transmit negative differential line |
|
11 |
PPS_IN |
External PPS signal input |
|
4 |
TOV |
General-purpose IO, 3.3 V logic level, rising edge active |
|
3, 12, 13 |
GND |
Common ground for communication circuit and power circuit |
After the supply voltage drops below the device operating threshold, the power-off holding time t_OFF before re-powering shall not be less than 3 seconds. Insufficient power-off interval will lead to abnormal startup, latch-up or initialization failure of the device.
External Communication Interface
3.4.1 XDGYRO-55AA Protocol
The XDGYRO-55AA protocol of the MTG200 three-axis gyro assembly broadcasts IMU data periodically by default. The default output rate is 200 Hz, baud rate 115200 bps. Each frame consists of 1 start bit, 8 data bits, 1 stop bit, no parity bit.
Table 3 XDGYRO-55AA Communication Protocol for MTG200 MEMS Three-Axis Gyro Assembly
|
Index |
Byte Offset |
Byte Count |
Content |
Scale Factor |
Range |
Unit |
Remarks |
|
1 |
0 |
1 |
0x55 |
1 |
- |
- |
Frame Header |
|
2 |
1 |
1 |
0xAA |
1 |
- |
- |
Frame Header |
|
3 |
2 |
1 |
0x14 |
1 |
- |
- |
Payload Length |
|
4 |
3~6 |
4 |
PCnum |
1 |
- |
- |
Frame counter |
|
5 |
7~10 |
4 |
X Angular Rate |
0.000001 |
- |
°/s |
- |
|
6 |
11~14 |
4 |
Y Angular Rate |
0.000001 |
- |
°/s |
- |
|
7 |
15~18 |
4 |
Z Angular Rate |
0.000001 |
- |
°/s |
- |
|
8 |
19~22 |
4 |
Reserved Bytes |
- |
- |
- |
Reserved |
|
9 |
23 |
1 |
Checksum |
1 |
[0, 255] |
- |
Lower 8 bits of cumulative sum of bytes offset 2 ~ 22 |
3.4.2 WXGYRO-EB90 Protocol
Data Link Layer
Transmission complies with UART Idle-Line mode, and the frame format of SCI bus is defined as below. The basic transmission unit is a character, with 11 bits per character.
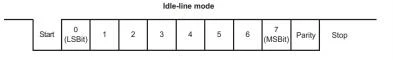
Figure 3 Data Transmission Format
Under Idle-Line transmission mode, each frame occupies 1 byte and all frames are treated as data frames. One SCI data frame is 1 byte (8 bits). The bus remains logic high during idle state. All SCI frames start with a logic-low start bit, followed by frame data transmitted with Least Significant Bit First (LSB First). Detailed frame definition:
Start bit: 1 bit
Data bits: 8 bits (b0~b7)
Stop bit: 1 bit
Parity bit: Odd parity
Baud rate: 115200 bps
For multi-byte transmission, high byte is transmitted prior to low byte by default.
Application Layer
Single Unit Telemetry Data Format
Single unit telemetry data is the response data of each component/module after receiving telemetry request commands from the on-board computer. The detailed format is shown in the table below.
Table 4 Single Unit Telemetry Data Format
|
Byte Index |
Definition |
Description |
|
B0, B1 |
Frame Header |
Fixed value: EB90H |
|
B2, B3 |
Payload Length |
Note 1 |
|
B4 |
Telemetry Data Classification ID |
Note 2 |
|
B5 |
Telemetry Request Command Counter |
Note 3 |
|
B6 |
Valid Command Counter |
Note 4 |
|
B7 |
Invalid Command Counter |
Note 5 |
|
B8 |
Latest Executed Command Code |
Note 6 |
|
B9 ~ B(N-1) |
User-Defined Payload |
Note 7 |
|
BN |
Checksum |
Note 8 |
|
Note: The gyro assembly only supports telemetry request commands without other control commands, so Bytes B6, B7, B8 shall be filled with 0xFF. |
||
Note 1: Payload Length. Total byte count ranging from Telemetry Data Classification ID (inclusive) to Checksum (inclusive).
Note 2: Telemetry Data Classification ID. Shall be consistent with the corresponding field in the telemetry request command.
Note 3: Telemetry Request Command Counter. 1 unsigned byte, increments by 1 upon receiving the matching telemetry request frame sent by the on-board computer.
Note 4: Valid Command Counter. 1 unsigned byte, increments by 1 upon receiving a complete valid command excluding telemetry request frames (validated by checksum). Fill with 0xFF for units without remote control commands.
Note 5: Invalid Command Counter. 1 unsigned byte, counts abnormal received data including wrong frame header, checksum error, unrecognized command code, etc. Fill with 0xFF for units without remote control commands.
Note 6: Latest Executed Command Code. 1 unsigned byte, records the code of the latest control command (excluding telemetry request and broadcast messages). This field is updated immediately after command verification passes (not after command execution succeeds). If command verification fails, errors shall be indicated via Invalid Command Counter in user-defined payload; fill with 0xFF for units without remote control commands.
Note 7: User-Defined Payload. Bytes B9 ~ B(N-1), customizable based on user requirements.
Note 8: Checksum. Unsigned cumulative sum of all bytes (B0+B1+B2+…+B(N-1)), retain the lower 8 bits for this byte.
The telemetry response data shall be output within 2 ms after receiving a telemetry request command; otherwise, the communication shall be judged as timeout.
Single Unit Remote Control Command Format
Telemetry Request Command
The telemetry request command is a data frame sent by the on-board computer to acquire telemetry packets from each unit, transmitted once per second by default. Separate sampling frequencies are specified for telemetry packets requiring special acquisition rates. The telemetry request format is shown below.
Table 5 Telemetry Request Data Format
|
B0 |
B1 |
B2 |
B3 |
B4 |
B5 |
B6 |
B7 |
|
EB |
90 |
TMT |
00 |
00 |
00 |
00 |
SUM |
Telemetry Data Classification ID (TMT): Identifies the type of returned telemetry data. Set to 0xFF if only one type of telemetry exists. For multiple telemetry types: Type 1 = 0xFF, Type 2 = 0xFE, Type 3 = 0xFD, and so on. This field in telemetry response frames must match the corresponding field in telemetry request frames for each telemetry type.
SUM: Checksum. Unsigned cumulative sum of B0~B6, retain the lower 8 bits for this byte.
Note: Byte B2 is fixed as 0xFF.
Single Unit Telemetry Response Data
Upon receiving a telemetry request command, telemetry data shall be transmitted in the format below; the user-defined payload segment is specified as follows:
Table 6 Gyro Output Telemetry Data
|
Index |
Byte Count |
Content |
Scale Factor |
Range |
Unit |
Remarks |
|
1 |
4 |
PCnum |
1 |
- |
- |
Frame counter for data continuity verification |
|
2 |
4 |
X Angular Rate |
0.000001 |
- |
°/s |
- |
|
3 |
4 |
Y Angular Rate |
0.000001 |
- |
°/s |
- |
|
4 |
4 |
Z Angular Rate |
0.000001 |
- |
°/s |
- |
|
5 |
2 |
X Gyro Temperature |
0.008 |
- |
℃ |
- |
|
6 |
2 |
Y Gyro Temperature |
0.008 |
- |
℃ |
- |
|
7 |
2 |
Z Gyro Temperature |
0.008 |
- |
℃ |
- |
|
8 |
2 |
Reserved Bytes |
- |
- |
- |
Reserved |
3.4.3 STIMGYRO-90 Protocol
The STIMGYRO-90 protocol of the MTG200 three-axis gyro assembly broadcasts IMU data periodically by default. The default output rate is 200 Hz, baud rate 460800 bps. Each frame consists of 1 start bit, 8 data bits, 1 stop bit, no parity bit.
Table 7 STIMGYRO-90 Communication Protocol for MTG200 MEMS Three-Axis Gyro Assembly
|
Index |
Field Name |
Byte Count |
Range |
Scale Factor |
Remarks |
|
0 |
Frame Header |
1 |
0x90 |
- |
- |
|
1-3 |
X-Axis Gyro Angular Rate |
3 |
-500°/s ~ 500°/s |
16384 |
- |
|
4-6 |
Y-Axis Gyro Angular Rate |
3 |
Same as X-axis |
16384 |
- |
|
7-9 |
Z-Axis Gyro Angular Rate |
3 |
Same as X-axis |
16384 |
- |
|
10 |
Self-Test Status |
1 |
0x00: Self-test pass; 0x11: Self-test fault |
- |
- |
|
11 |
CRC Checksum |
1 |
CRC-8/ROHC, polynomial x⁸+x²+x+1, initial seed=0xFF |
- |
- |
3.4.4 XDGYRO-99 Protocol
The XDGYRO-99 protocol of the MTG200 three-axis gyro assembly broadcasts IMU data periodically by default. The default output rate is 2 kHz, baud rate 921600 bps. Each frame consists of 1 start bit, 8 data bits, 1 stop bit, no parity bit.
Table 8 XDGYRO-99 Communication Protocol for MTG200 MEMS Three-Axis Gyro Assembly
|
Parameter Name |
Valid Range |
Byte Count |
Scale Factor |
Remarks |
|
Frame Header |
0x99 |
1 |
- |
- |
|
X-Axis Angular Rate |
[-512, 512] |
3 |
2⁻¹⁴ |
Unit: °/s, high byte transmitted first; MSB of the first byte serves as sign bit. Calculation algorithm see Note a) |
|
Y-Axis Angular Rate |
[-512, 512] |
3 |
2⁻¹⁴ |
Same as X-axis |
|
Z-Axis Angular Rate |
[-512, 512] |
3 |
2⁻¹⁴ |
Same as X-axis |
|
Gyro Status Word |
- |
1 |
- |
All zeros indicate normal operation; detailed definition below |
|
X-Axis Temperature |
[-128, 128] |
2 |
2⁻⁸ |
Unit: ℃, high byte transmitted first; MSB of the first byte serves as sign bit. Calculation algorithm see Note b) |
|
Y-Axis Temperature |
[-128, 128] |
2 |
2⁻⁸ |
Same as X-axis temperature |
|
Z-Axis Temperature |
[-128, 128] |
2 |
2⁻⁸ |
Same as X-axis temperature |
|
Frame Counter |
[0, 255] |
1 |
1 |
Continuous counter from 0 to 255 |
|
Checksum |
- |
1 |
- |
CRC check with designated polynomial |

Table 9 Product Status Bit Definition
|
Bit Position |
Definition |
|
Bit 7 |
0 = Normal; 1 = Global system fault |
|
Bit 6 |
0 = Normal; 1 = Startup in progress |
|
Bit 5 |
0 = Normal; 1 = Abnormal external environment |
|
Bit 4 |
0 = Normal; 1 = All three axes out of operating range |
|
Bit 3 |
0 = Normal; 1 = Fault in three-axis output data |
|
Bit 2 |
0 = Normal; 1 = Z-axis out of range or fault |
|
Bit 1 |
0 = Normal; 1 = Y-axis out of range or fault |
|
Bit 0 |
0 = Normal; 1 = X-axis out of range or fault |
Calculation Notes
Gyro angular rate output value[°/s]=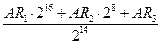 ,
Where: = Upper 8 bits among the 3 output bytes of each gyro axis angular rate;
 = Middle 8 bits among the 3 output bytes of each gyro axis angular rate;
 = Lower 8 bits among the 3 output bytes of each gyro axis angular rate.
Gyro temperature output value[℃]= ,
Where: = Upper 8 bits among the 2 output bytes of each gyro axis temperature;
 = Lower 8 bits among the 2 output bytes of each gyro axis temperature.
3.4.5 XDGYRO-A0 Protocol
The XDGYRO-A0 protocol of the MTG200 three-axis gyro assembly broadcasts data periodically via RS422 asynchronous communication interface. Baud rate: 460800 bps, 1 start bit, 8 data bits, 1 stop bit, no parity bit, data update rate 1000 Hz.
Table 10 XDGYRO-A0 Communication Protocol for MTG200 MEMS Three-Axis Gyro Assembly
|
Byte Index |
Field Name |
Data Type |
Value / Scale Factor |
|
0 |
Frame Header 0 |
8-bit unsigned integer |
0xA0 |
|
1~3 |
X-Axis Angular Rate |
32-bit signed integer |
0.00006103515625 °/s |
|
4~6 |
Y-Axis Angular Rate |
32-bit signed integer |
0.00006103515625 °/s |
|
7~9 |
Z-Axis Angular Rate |
32-bit signed integer |
0.00006103515625 °/s |
|
10 |
Status Word |
8-bit unsigned integer |
0x00 = Normal0x01 = X-axis data fault0x02 = Y-axis data fault0x04 = Z-axis data fault |
|
11 |
Check Value |
8-bit unsigned integer |
XOR result of three-axis angular rate data and status word |
|
12 |
Frame Tail |
8-bit unsigned integer |
0xB0 |
Product Operation Precautions
- Strictly follow the electrical pin assignment of the product during wiring to avoid misconnection.
- This product is a precision inertial measurement device. Avoid shocks, collisions and mechanical loads exceeding its rated tolerance during handling.
- The mounting flatness has significant influence on angular rate measurement. A high-flatness mounting plane is required to eliminate installation misalignment errors.
- Mount the product firmly and reliably to prevent measurement errors induced by loose installation.
- Take anti-static protection during installation and operation; anti-static wrist strap is recommended.
- Operate strictly in accordance with the specifications of this manual and verify that the ambient conditions match the operating requirements. Do not disassemble the housing or modify internal structures if faults occur. Contact our technical support engineers promptly for troubleshooting.
Hot Tags: mtg200 mems gyro, China mtg200 mems gyro manufacturers, factory