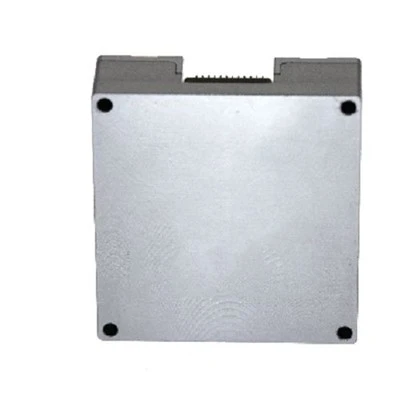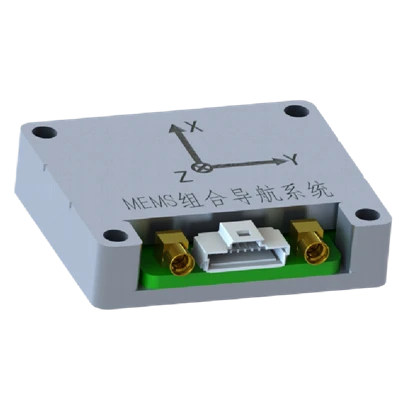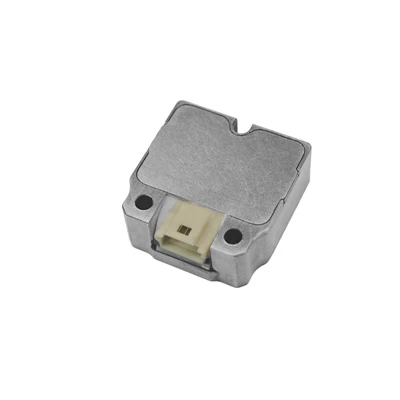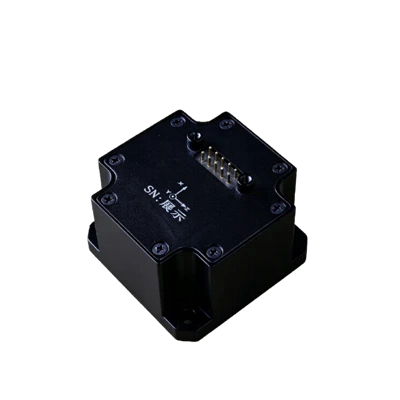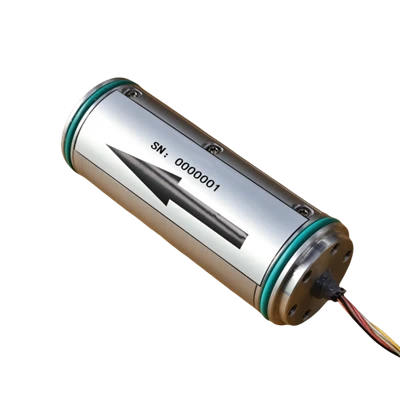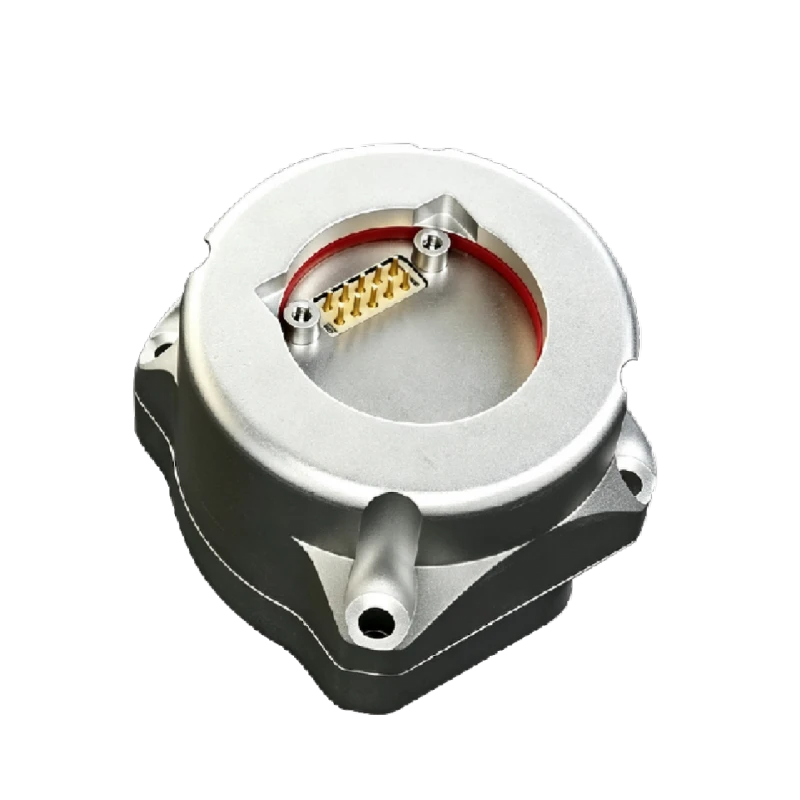
MSU300 High Precision MEMS Inertial Measurement Unit
High-Precision MEMS IMU
100% domestically produced components
High performance, compact size, low power consumption
Description
Key Features
- High-Precision MEMS IMU
- 100% domestically produced components
- High performance, compact size, low power consumption
- -45°C to +80°C full temperature range calibration and compensation
- 1K Hz high-speed sampling
- Harsh mechanical environment resistance
- Online firmware update
Applications
- Guided weapons under harsh mechanical and temperature conditions
- UAV/UGV/USV Attitude Reference
- Attitude Control
- Radar/IR Antenna Stabilization Platform
Product Overview
MSU300 is a highly reliable and cost-effective six-axis MEMS inertial sensor, widely applicable in navigation, control, and measurement fields represented by inertial navigation and attitude stabilization.
MSU300IMU employs enhanced structural design, structural adhesive sealing design, and other measures to ensure that the product can accurately measure the angular and linear motion parameters of the host vehicle even in harsh environments, thereby providing users with a highly reliable solution. It can be configured with different hardware and software settings according to user requirements, thereby meeting the needs of different users to the greatest extent.
MSU300 MEMS Inertial Measurement Unit
|
MEMS Gyroscope |
|
|
Range (°/s) |
±400 |
|
Bias (°/h) |
≤2 |
|
Bias Stability (°/h, 10s smoothing) |
≤0.3 |
|
Bias Instability (°/h,Allan) |
≤0.03 |
|
Angle Random Walk (°/√h) |
≤0.3 |
|
Bias Repeatability (°/h) |
≤0.02 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Axis Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
MEMS Accelerometer |
|
|
Range (g) |
±30 |
|
Bias (mg) |
≤2 |
|
Bias Stability (μg) |
≤50 |
|
Bias Instability (μg, Allan) |
≤30 |
|
Velocity Random Walk (m/s/√h) |
≤50 |
|
Bias Repeatability (μg) |
≤0.03 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Bandwidth (Hz) |
≤0.001 |
|
Cross-Axis Coupling (rad) |
≥200Hz |
|
Electrical/Mechanical Interface |
|
|
Power Supply (V) |
5±0.2V |
|
Power (W) |
≤2 |
|
Startup Time (s) |
≤2 |
|
Communication Interface |
2-channel RS-422 |
|
Update Rate (Hz) |
200 (customizable, maximum 1000) |
|
Dimensions (mm x mm x mm) |
56×56×38.5 |
|
Weight (g) |
236±5g |
|
Operating Environment |
|
|
Operating Temperature (°C) |
-45~80 |
|
Storage Temperature (°C) |
-55~85 |
|
Vibration (g, Rms) |
13 |
|
Shock (g) |
1000g/1ms (energized) |
Product Introduction
Product Overview
The MSU300 MEMS Inertial Measurement Unit is a highly reliable and cost-effective six-axis MEMS inertial sensor, widely applicable in navigation, control, and measurement fields represented by inertial navigation and attitude stabilization.
The MSU300 Inertial Measurement Unit integrates high-performance MEMS gyroscopes and MEMS accelerometers within an independent structure. The gyroscopes and accelerometers selected for the module represent the leading level of MEMS-process inertial devices. All electronic components within the module achieve 100% domestic production. The three-axis MEMS gyroscope senses the angular motion of the host vehicle, and the three-axis MEMS accelerometer senses the linear acceleration of the host vehicle. The module performs internal compensation for zero-offset, scale factor, non-orthogonality error, and acceleration-related parameters over the full temperature range, maintaining high measurement accuracy over extended periods. Additionally, the module employs enhanced structural design, structural adhesive sealing design, and other measures to ensure that the product can accurately measure the angular and linear motion parameters of the host vehicle even in harsh environments, thereby providing users with a highly reliable solution.
The MSU300 Inertial Measurement Unit can be configured with different hardware and software settings according to user requirements, thereby meeting the needs of different users to the greatest extent.
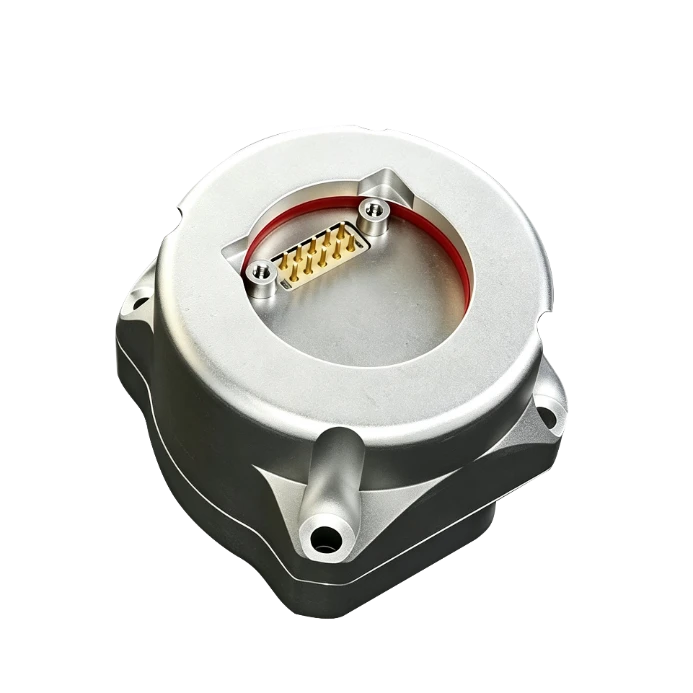
Key Features
- High precision MEMS IMU
- 100% Domestically produced components
- High performance, compact size, low weight, low power consumption
- -45°C to +80°C full temperature range calibration and compensation
- 1K Hz high-speed sampling
- Harsh mechanical environment resistance
- Online firmware update capability
Product Composition
MSU300 Inertial Measurement Unit Primarily composed of a three-axis MEMS gyroscope, three-axis MEMS accelerometer, information processing circuit, Navigation software, structural components, test cable, and test software.
Default outputs are provided as follows:
- 3D Angular Rate
- 3D Acceleration
- Gyroscope Temperature
- Accelerometer Temperature
Applications
The main application areas of the MSU300 Inertial Measurement Unit are as follows:
- Guided weapons under harsh mechanical and temperature conditions
- UAV/UGV/USV Attitude Reference
- Attitude Control
- Radar/IR Antenna Stabilization Platform
Technical Specifications
Table 1 MSU300 Series Inertial Measurement Unit Performance Specifications
|
Gyroscope |
|
|
Range (°/s) |
±400 |
|
Bias (°/h) |
≤2 |
|
Bias Stability (°/h, 10s smoothing) |
≤0.3 |
|
Bias Instability (°/h,Allan) |
≤0.03 |
|
Angle Random Walk (°/√h) |
≤0.3 |
|
Bias Repeatability (°/h) |
≤0.02 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-Axis Coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥200Hz |
|
MEMS Accelerometer |
|
|
Range (g) |
±30 |
|
Bias (mg) |
≤2 |
|
Bias Stability (μg) |
≤50 |
|
Bias Instability (μg, Allan) |
≤30 |
|
Velocity Random Walk (m/s/√h) |
≤50 |
|
Bias Repeatability (μg) |
≤0.03 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Bandwidth (Hz) |
≤0.001 |
|
Cross-Axis Coupling (rad) |
≥200Hz |
|
Electrical/Mechanical Interface |
|
|
Power Supply (V) |
5±0.2V |
|
Power (W) |
≤2 |
|
Startup Time (s) |
≤2 |
|
Communication Interface |
2-channel RS-422 |
|
Update Rate (Hz) |
200 (customizable, maximum 1000) |
|
Dimensions (mm x mm x mm) |
56×56×38.5 |
|
Weight (g) |
236±5g |
|
Operating Environment |
|
|
Operating Temperature (°C) |
-45~80 |
|
Storage Temperature (°C) |
-55~85 |
|
Vibration (g, Rms) |
13 |
|
Shock (g) |
1000g/1ms (energized) |
Mechanical Characteristics
The MSU300 Inertial Measurement Unit housing adopts a high-strength aerospace aluminum alloy structure, and the internal IMU uses a stainless-steel structure, providing high structural integrity. The internal components undergo shock absorption treatment, with resistance to vibration and shock. The module mechanical dimensions are shown in Figure 1, and the module is secured with 4 M4 screws.
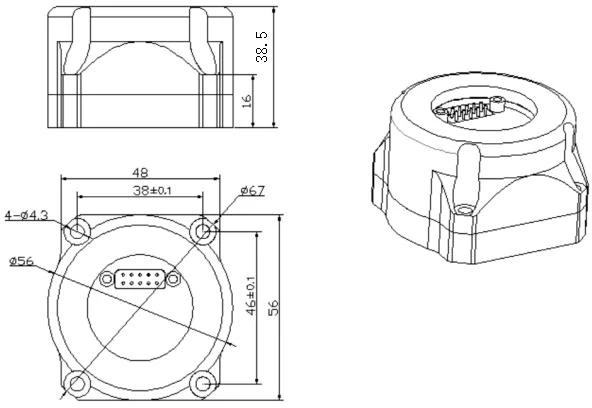
Figure 1 Module Mechanical Dimensions
Product Marking and Polarity
The product coordinate system is shown in the figure below. The product uses a standard adhesive label by default, and laser marking is also supported.
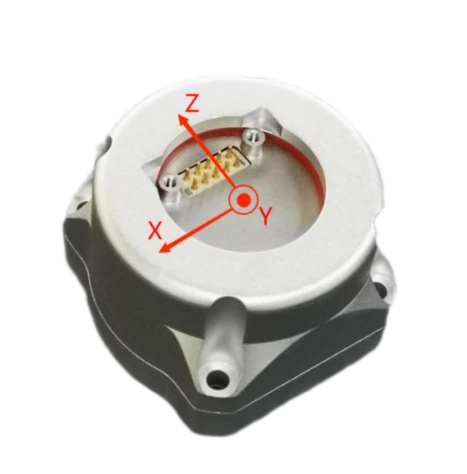
Figure 2 Product Coordinate System
Interface Definition
The MSU300 Inertial Measurement Unit uses a customized CH-26A-10TJ dual-row pin header connector (mating connector CH-26A-10ZK) for external output, primarily for module power supply and external communication. The connector pin definitions are shown in Table 2.
Table 2 MSU300 Inertial Measurement Unit Connector Pin Definitions
|
Pin No. |
Definition |
Remarks |
|
1 |
VSUP |
Power Positive,+5~12V |
|
2 |
COM1_Rx+ |
RS422-1 Receive Positive |
|
3 |
COM1_Tx+ |
RS422-1 Transmit Positive |
|
4 |
COM2_Rx+ |
RS422-2 Receive Positive |
|
5 |
COM2_Tx+ |
RS422-2 Transmit Positive/Sync Signal Output+ |
|
6 |
GND |
Power Ground |
|
7 |
COM1_Rx- |
RS422-1 Receive Negative |
|
8 |
COM1_Tx- |
RS422-1 Transmit Negative |
|
9 |
COM2_Rx- |
RS422-2 Receive Negative |
|
10 |
COM2_Tx- |
RS-422-2 Transmit Negative / Sync Signal Output - |
|
Note: Factory default output is RS-422-1 and differential sync signal. |
||
Communication Protocol
The MSU300 Inertial Measurement Unit defaults to periodic broadcast output of IMU data at an output frequency of 1000 Hz, with each data frame containing 40 bytes, a baud rate of 460800 bps, 1 start bit, 8 data bits, 1 stop bit, and no parity. For multi-byte variables, the low byte is transmitted first followed by the high byte. The typical communication protocol is shown in Table 3.
The communication baud rate and communication period can also be configured by the user, with a maximum baud rate of 921600 bps and a maximum communication frequency of 1000 Hz.
Table 3 MSU300 High-Precision MEMS Inertial Measurement Unit Communication Protocol
|
No. |
Byte Start |
Byte Count |
Content |
Equivalent |
Range |
Unit |
Remarks |
|
1 |
0 |
1 |
0x55 |
1 |
Frame Header |
||
|
2 |
1 |
1 |
0xAA |
1 |
Frame Header |
||
|
3 |
2 |
1 |
36 |
1 |
Data Length |
||
|
4 |
3 |
4 |
PCnum |
1 |
1ms Count Value |
||
|
5 |
7 |
4 |
Angular Rate X |
0.000001 |
[-1000,1000] |
°/s |
|
|
6 |
11 |
4 |
Angular Rate Y |
0.000001 |
[-1000,1000] |
°/s |
|
|
7 |
15 |
4 |
Angular Rate Z |
0.000001 |
[-1000,1000] |
°/s |
|
|
8 |
19 |
4 |
Acceleration X |
0.000001 |
[-40g,40g] |
m/ |
|
|
9 |
23 |
4 |
Acceleration Y |
0.000001 |
[-40g,40g] |
m/ |
|
|
10 |
27 |
4 |
Acceleration Z |
0.000001 |
[-40g,40g] |
m/ |
|
|
11 |
31 |
2 |
Gyroscope Temperature |
0.008 |
[-120,120] |
℃ |
|
|
12 |
33 |
2 |
Accelerometer Temperature |
0.008 |
[-120,120] |
℃ |
|
|
13 |
35 |
4 |
IMU Information Code |
1 |
- |
- |
Spare |
|
14 |
39 |
1 |
Checksum |
1 |
[0,255] |
Low 8 bits of the cumulative sum of bytes indexed 2 to 38 |


Precautions
- Pay attention to the product electrical interface definitions. During use, strictly follow the pin arrangement to avoid incorrect connections;
- The product is a precision measurement device. During operation, ensure that no impact, collision, or other conditions exceeding the product's tolerance range occur;
- Product installation significantly affects angular rate measurement. To avoid introducing installation errors, the mounting surface must have good flatness;
- To ensure measurement accuracy, the product must be installed securely and firmly to avoid measurement errors caused by looseness;
- During product installation and operation, ESD protection should be observed; wearing an ESD wrist strap is recommended;
- Please strictly follow the requirements of this manual for operation, and confirm that the external environment matches the usage requirements. If any issues arise, do not open the product cover, modify the internal structure, or perform similar operations. If problems occur, please contact our technical support personnel promptly.
Hot Tags: msu300 high precision mems inertial measurement unit, China msu300 high precision mems inertial measurement unit manufacturers, factory